


SC753B-001-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
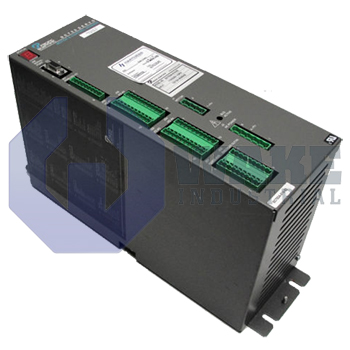
The Pacific Scientific SC753B-001-01 is a servocontroller in the SC750 Servo Drives series and functions as a programmable digital position controller. It operates with a continuous current of 7.5 A and a peak current of 15 A, supporting resolver feedback. The unit uses natural convection cooling and offers a peak power output of 4500 Watts with a max power dissipation of 77 Watts.
Internal Product Review
The SC753B-001-01 is a Pacific Scientific servocontroller built as a programmable digital position controller. Resolver feedback and 24K user memory support precise motion tuning and efficient application setup. Continuous current of 7.5 A and peak current of 15 A provide strong servo response under changing load conditions.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
Pacific Scientific produced the SC753B-001-01 as part of its SC750 Servo Drives series. This unit functions as a programmable digital position controller, delivering closed-loop motion commands to matched motors in material-handling, packaging, and assembly systems. Its digital control architecture supports repeatable starts, stops, and position changes during automated motion tasks. Within the product code, the B hardware level and 01 control revision identify the build configuration, and the unit is intended for panel installation where normal cabinet airflow is available.
The drive supplies a continuous output of 7.5 A, giving steady current for mid-frame servo motors, and it can deliver up to 15 A during short accelerations or brief load disturbances. That peak current supports a maximum instantaneous shaft demand of 4500 Watts before the current regulator limits the stage. Internally, switching elements and control logic release up to 77 Watts of heat, so the chassis relies on natural convection and needs unobstructed vertical air movement in the enclosure. A 3 kVA isolation transformer is recommended to support inrush demand and protect the power stage.
Motion feedback is handled through a resolver feedback interface that excites the transducer, demodulates the return signals, and tracks rotor position for closed-loop control. Resolver sensing is well suited to electrically noisy industrial environments because the analog return signals remain stable during speed changes. Application logic is written in PacSci ServoBASIC Plus, allowing position loops, calculated profiles, and discrete I/O handling to execute directly in the controller’s 24K of nonvolatile user memory, so programs, data arrays, and diagnostic buffers must share that space. When fully equipped with its terminal blocks and baseplate, the drive weighs 7.26 kg, which should be considered when mounting it on a panel or support structure.









