


R46SSNA-TS-MD-NV-02 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
- Straightforward Pricing: No Rush Fees, No Credit Card Fees
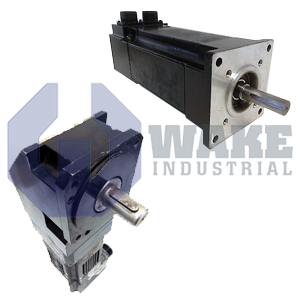
The Pacific Scientific R46SSNA-TS-MD-NV-02 is a servo motor from the R Servomotors series with a frame size of 4.25 inches square and a 6 inch stack length. It delivers a continuous stall torque of 7.6 Nm and a peak torque of 20.2 Nm, and uses rare earth samarium cobalt magnets. The motor features a Tachsyn primary feedback and comes without a holding brake or shaft seal.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The R46SSNA-TS-MD-NV-02 is a rotary actuator manufactured by Pacific Scientific and assigned to the R Servomotors series. Engineered for industrial automation, the unit converts drive commands from a servo amplifier into controlled shaft motion so that conveyor sections, indexing tables, or robotic joints follow programmed speed and position profiles. Its electromechanical design gives machine builders a compact motor that mates with standard 4-bolt flanges and supports rapid duty cycling.
During continuous operation, the motor can deliver a stall torque of 7.6 Nm, which suits medium-inertia loads that must hold position without drift when stopped. The square mounting face measures 4.25-inch square, allowing direct replacement of earlier NEMA-frame motors on existing gearboxes or linear actuators. For short bursts, it produces up to 20.2 Nm of peak torque, enabling fast acceleration of payloads. A reflected rotor inertia of 0.40 × 10⁻³ kg·m² helps the drive close velocity loops quickly because less energy is required to reverse direction. Torque density is further increased by samarium cobalt rare-earth magnets, whose high residual flux produces stronger electromagnetic attraction than ferrite alternatives.
The standard aluminum housing simplifies thermal conduction while maintaining alignment of the laminated stack, which is 6 inches long. Rotor position is reported through a Tachsyn transducer, giving velocity feedback and incremental angle data to the servo drive for closed-loop control. Because the unit is supplied with no brake, any static holding function must be provided by the mechanical system or by drive current. The absence of a shaft seal means the mounting location should exclude fluid spray or airborne contaminants that could migrate along the shaft into the bearing cavity.









