


R45GSNA-R2-NS-NV-03 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
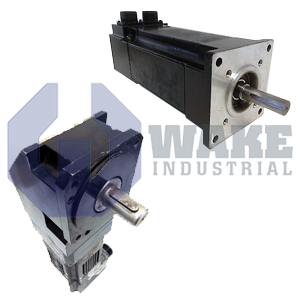
The Pacific Scientific R45GSNA-R2-NS-NV-03 is a servo motor in the R Servomotors series with a frame size of 4.25 inches square and a stack length of 5 inches. It features a continuous stall torque of 5.7 Nm, a peak torque of 15.1 Nm, and uses a rare earth samarium cobalt magnet material. The motor provides frameless resolver feedback, has an inertia of 0.31 kgm² x 10⁻³, and is built with standard winding and housing.
Internal Product Review
The R45GSNA-R2-NS-NV-03 is a Pacific Scientific servo motor rated for 5.7 Nm continuous stall torque. Rare-earth samarium cobalt magnet construction and 15.1 Nm peak torque give the design strong dynamic performance in demanding motion systems. Frameless resolver feedback adds dependable position sensing, making this a very capable servomotor for precise industrial duty.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The R45GSNA-R2-NS-NV-03 is a brushless AC servo motor produced by Pacific Scientific for its R Servomotors series. Within an automation cell, this unit couples to a matching digital drive to generate closed-loop motion for conveyors, pick-and-place actuators, or index tables with repeatable accuracy. Its construction follows the series pattern of square-frame housings and rare-earth magnets, which helps maintain consistent mechanical interfacing across the product line. The motor’s electromechanical profile makes it suitable for medium-inertia loads that demand rapid acceleration.
The motor body measures 4.25 inches square across the mounting face, a dimension that determines compatible flange patterns and limits installation footprint. Axial length is set by its 5-inch stack, which provides space for the windings that establish torque density. Under continuous excitation, the rotor can sustain 5.7 Nm of stall torque without thermal overload, while short bursts permit up to 15.1 Nm so the axis can overcome static friction or accelerate loads. System dynamic response is helped by a reflected rotor inertia of 0.31 kg·m² × 10⁻³, which balances torque production with the need to minimize overshoot.
Torque is generated with rare-earth samarium cobalt magnets, which maintain flux over wide temperature ranges and resist demagnetization during peak current events. Position feedback is supplied by a frameless transmitter-type resolver, size 21, giving analog sine-cosine outputs for the drive control loop and eliminating the need for secondary transducers. The motor is shipped without a holding brake, so external mechanical constraints or drive torque must secure the load during power-off states. It also operates without a shaft seal, so the installation should avoid direct liquid ingress or use external sealing if required. Housing and winding styles are standard, and no secondary feedback devices are integrated.









