


R35KENC-R2-NS-NV-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
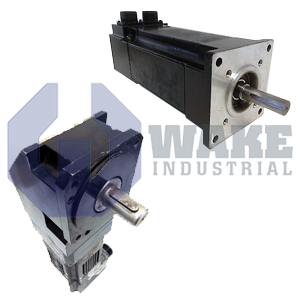
The Pacific Scientific R35KENC-R2-NS-NV-00 is a servo motor from the R Servomotors series featuring a continuous stall torque of 3.8 Nm and a 3.25 inch square frame. It uses rare earth samarium cobalt magnets and has a rated speed of 4200 RPM. The motor includes a frameless resolver for primary feedback and has a stack length of 5 inches.
Internal Product Review
The R35KENC-R2-NS-NV-00 is a Pacific Scientific servo motor from the R Servomotors series with a rated speed of 4200 RPM. Continuous stall torque of 3.8 Nm and peak torque of 10.1 Nm support strong acceleration and stable servo response. Rare-earth samarium cobalt magnets and a frameless resolver primary feedback design make this motor a very capable choice for precise motion control.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The R35KENC-R2-NS-NV-00 is a servo motor built by Pacific Scientific and placed within the R Servomotors series. As a brushless AC unit, it converts drive-amplifier current into controlled rotary motion for industrial positioning tasks such as indexing, feed control, and axis positioning. The motor uses a size 21 frameless resolver for primary feedback, enabling closed-loop velocity and position regulation without an added encoder. Factory configuration omits a holding brake and a shaft seal, so static load retention and external sealing must be provided by the machine.
At standstill, the motor can deliver a continuous stall torque of 3.8 Nm, which is sufficient to maintain load without overheating under rated current. During rapid acceleration, it reaches a peak torque of 10.1 Nm, providing a wide dynamic margin for short-term demand. The rotor inertia is 0.13 × 10⁻³ kg·m², so commanded speed changes are executed with minimal lag, especially when paired with the medium-high stator winding. That winding supports a rated mechanical speed of 4200 rpm, balancing voltage requirements and back EMF. The electrical design is Medium-High, indicating an intermediate wire gauge and turn count suited to versatile servo drives.
The mechanical form follows an inch-based mounting pattern with base holes sized for a 3.25-inch square frame. A cylindrical shaft extends from the housing, and the active magnetic stack measures 5 inches along the motor axis, which supports higher torque density without increasing frame width. Magnets made from samarium cobalt rare-earth material improve thermal stability and resistance to demagnetization compared with ceramic alternatives. The housing style is coded as C, providing a straight-through layout for airflow when the motor is mounted in cabinets. Because there is no secondary feedback device, the control loop relies on the resolver signal for rotor position information.









