


R33HSNC-HS-NF-NV-02 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
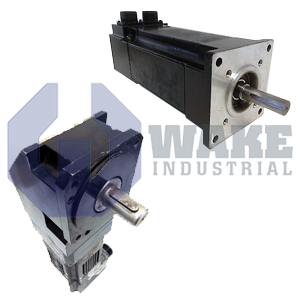
The Pacific Scientific R33HSNC-HS-NF-NV-02 is a servo motor from the R Servomotors series with a 3.25 inch square frame and a 3 inch stack length. It features a high speed winding type, rated speed of 6000 RPM, and uses rare earth samarium cobalt magnets. The motor delivers a continuous stall torque of 2.5 Nm and peak torque of 6.54 Nm, with primary hall sensors and a secondary 1000 ppr line driver encoder feedback.
Internal Product Review
The R33HSNC-HS-NF-NV-02 is a Pacific Scientific servo motor tuned for high-speed motion control, with a high-speed winding and a 6000 RPM rated speed. Continuous stall torque of 2.5 Nm and peak torque of 6.54 Nm support stable acceleration and dependable servo response under varying load conditions. Hall sensor primary feedback paired with a 1000 ppr encoder provides clean commutation and accurate position feedback.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The R33HSNC-HS-NF-NV-02 is an AC servo motor produced by Pacific Scientific as part of the R Servomotors series. The unit belongs to the three-inch stack group within the family and is intended for compact, high-speed axes. By converting drive current into precisely regulated torque, it provides closed-loop motion for pick-and-place actuators, light gantries, and material-handling equipment in general industrial automation. Its square frame simplifies mounting to existing machine plates and keeps weight centered on the load.
In continuous duty, the motor develops 2.5 Nm of stall torque, so it can hold or creep under rated load without additional gearing. The winding supports a rated mechanical speed of 6000 rpm, enabling direct coupling to feed screws or belt drives that need rapid cycles. For transient events such as indexing moves, available output rises to 6.54 Nm, giving the drive extra headroom for acceleration. Dynamic behavior is influenced by the rotor’s reflected inertia of 0.093 kg·m² ×10⁻³, and this low value allows quick reversals while still helping limit overshoot. The motor uses a 3.25-inch square flange that lines up with common NEMA 34 hole patterns. Overall package depth comes from the three-inch laminated stack, and housing style C sets the external dimensions and conduit locations. No factory-installed brake is present, so shaft holding must be provided by the control loop or external locking hardware.
The electromagnetic circuit relies on rare-earth samarium cobalt magnets, whose high coercivity sustains torque across the full temperature span expected in enclosure-mounted equipment. Commutation signals come from three Hall sensors spaced 120 electrical degrees apart, while precise incremental feedback is delivered by the secondary 1000 ppr line-driver encoder, giving the controller both coarse and fine resolution channels for velocity and position loops. The stator is wound for high-speed operation, combining reduced turns with lower resistance to limit copper losses at elevated frequencies. Because there is no shaft seal, the motor should be installed where contaminants are controlled. The open front end lessens drag and eases thermal dissipation.









