


SF-A3.0093.030-10.053 Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: 1070076591
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
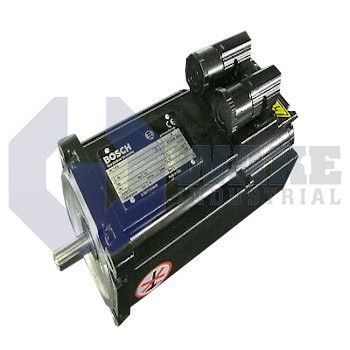
The Bosch Rexroth Indramat SF-A3.0093.030-10.053 is part of the SF Servo Motors series and operates at a DC link voltage of 670 V with a rated speed of 3000 rpm. It features an absolute value encoder with a precision of ±20 arcseconds and a resolution of 8,000,000 increments per revolution. The motor has a flange size of 116 mm and a smooth shaft diameter of 19 mm.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The SF-A3.0093.030-10.053 is a servo motor built by Bosch Rexroth Indramat and assigned to the SF Servo Motors series. As a brushless rotary actuator, the unit converts controlled electrical energy into torque for positioning, speed regulation, and coordinated motion tasks inside automated machinery. Integrated absolute feedback allows the drive controller to determine the shaft angle without a homing move, making the motor suitable for indexing stations, packaging machines, and material-handling axes where cycle time and repeatability are critical. This arrangement also helps the axis return to known position data after a power cycle, which supports consistent restart behavior in automated sequences.
Its power stage is designed around a DC bus of 670 V, so the connected drive must supply that link voltage for full dynamic range. An absolute encoder with a resolution of 8,000,000 increments per revolution and an angular accuracy of ±20 arcsec feeds precise position data to the control loop, supporting fine interpolation and low following error. During a locked-rotor event, the windings draw 6.0 A and can hold a stall torque of 8.1 Nm, which indicates the current demand and static holding capability at zero speed. The encoder operates in absolute mode, eliminating cumulative count errors after power cycling.
The motor reaches a rated speed of 3000 rpm and has a rotor inertia of 0.0016 kg·m², giving a balance between responsive acceleration and steady running at constant velocity. Installation uses a flange with a pilot diameter of 116 mm, while the output shaft is a 19 mm smooth shaft for coupling with clamped hubs. A torque constant of 1.35 Nm/A links commanded current to developed torque, allowing predictable response from the matched drive. The motor also withstands mechanical shock up to 6 g, and the flange and shaft arrangement supports direct mounting in compact servo modules without additional adapters.









