


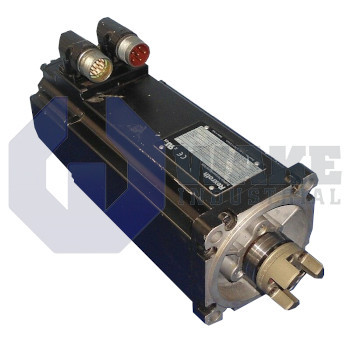
SF-A2.0026.030-14.053 Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: 1070082193
The Bosch Rexroth Indramat SF-A2.0026.030-14.053 is part of the SF Servo Motors series and has a rated speed of 3000 rpm. It delivers a locked-rotor torque of 2.6 Nm with a locked-rotor current of 1.7 A. The motor features a brake voltage of 24 VDC and a brake torque of 3.2 Nm.
Internal Product Review
The SF-A2.0026.030-14.053 is a Bosch Rexroth Indramat SF series servo motor known for its efficient performance in automation tasks. With a rated speed of 3000 rpm and a torque constant of 1.5 Nm/A, it delivers precise and responsive motion control. The integrated brake system features a 3.2 Nm brake torque at 24 VDC, making it ideal for applications requiring secure holding and rapid stopping.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The SF-A2.0026.030-14.053 is a synchronous servo motor produced by Bosch Rexroth Indramat as part of the SF Servo Motors series. In automated conveyors, pick-and-place modules, and light machining axes, it converts drive-controller current into precisely regulated rotary motion for accurate position and velocity control. The design incorporates a permanent-magnet rotor and an integral holding brake, so the motor can maintain load position during power-off states and still react quickly when the control loop is re-energized. Mechanical alignment follows standard flange dimensions, allowing installation in compatible servo frames.
The holding brake is energized at 24 VDC and requires just 0.56 A, providing efficient load retention when the axis is inactive. That brake clamps the shaft with 3.2 Nm of static torque, which is suitable for moderate vertical loads common in assembly cells. The rotor has an inertia of 4 ×10⁻⁴ kg·m², which affects how quickly the motor can accelerate or decelerate in response to command changes. During startup or a sudden stall, the windings may draw a locked-rotor current of 1.7 A; this transient value helps with drive sizing so thermal limits are not exceeded while the servo overcomes static friction and seating forces.
When rotation is prevented but voltage is applied, electromagnetic coupling can produce 2.6 Nm of locked-rotor torque, which can be used when setting stall detection thresholds. In continuous duty, the command speed reaches 3000 rpm, a nominal figure selected to balance motor heating with cycle time demands. A torque constant of 1.5 Nm/A means controller current setpoints translate predictably into mechanical output. These values support use with compatible IndraDrive amplifiers during repetitive dynamic loads.









