


MHD093C-035-PG0-B Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
- Straightforward Pricing: No Rush Fees, No Credit Card Fees
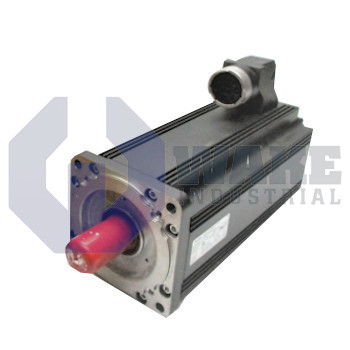
The Bosch Rexroth Indramat MHD093C-035-PG0-B is a servo motor from the MHD Synchronous Motors series. It features a flange size of 140 or 150 mm, a centering diameter of 130 mm, and a plain shaft with a shaft seal. The motor offers a continuous torque at standstill of 23.0 Nm and uses a digital servo feedback encoder with absolute position detection for more than 4096 revolutions.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The MHD093C-035-PG0-B is a servo motor manufactured by Bosch Rexroth Indramat for the MHD Synchronous Motors series. Designed for electrically commutated operation with compatible Rexroth drive controllers, the unit converts three-phase electrical energy into controlled rotary motion for positioning tables, feed axes, and automated transfer stations. An integrated encoder supplies the drive with high-resolution data so velocity and angular position can be regulated in real time. This arrangement supports repeatable indexing, smooth contouring, and stable motion control in industrial automation systems.
A centering diameter of 130 mm aligns the stator housing accurately during installation, while the square flange measures 140 / 150 mm to match common mounting patterns. Continuous torque at standstill reaches 23.0 Nm, allowing the motor to resist load movement during controlled dwell periods. Motion data are transmitted through digital servo feedback, which returns position information directly to the controller for closed-loop operation. Electrical behavior is linked to Winding Code 035, which indicates the resistance, inductance, and current characteristics used for this C-length frame. These electrical and mounting features make the motor suitable for machine axes that need accurate alignment and steady torque response.
The output side uses a plain shaft with a factory-installed seal that helps limit lubricant escape and contaminant entry. Because the motor is supplied without a holding brake, static holding must be provided by the mechanical system or by controlled drive torque when the axis is stopped. Power conductors connect through an output connector oriented toward side B, which can simplify cable routing when several motors are mounted in line. For multi-turn positioning, the feedback system provides Absolute (>4096 revolutions) data, so stored position information remains available after power returns. This helps the axis resume controlled operation without requiring a reference move at every startup.









