


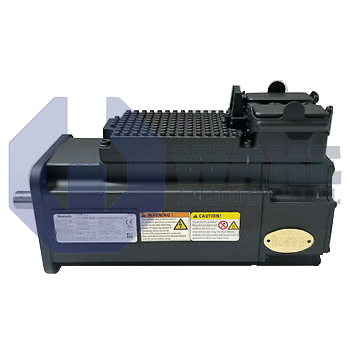
KSM02.1B-076C-35N-S1-HP0-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911339431
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-076C-35N-S1-HP0-ET-NN-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a hybrid connector for connection, uses natural convection for cooling, and operates with a DC supply voltage of 750 V. The drive is equipped with an optical, single-turn Hiperface encoder with 128 signal periods and communicates via Multi-Ethernet protocol.
Internal Product Review
The KSM02.1B-076C-35N-S1-HP0-ET-NN-D7-NN-FW is a Bosch Rexroth Indramat motor-integrated servo drive designed for clean, efficient machine integration. Multi-Ethernet communication and a DC 750 V supply support fast network connectivity and strong drive-side compatibility in modern automation platforms. Natural convection cooling and a Hiperface optical encoder make the unit a very practical choice for precise, low-maintenance motion control.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-076C-35N-S1-HP0-ET-NN-D7-NN-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat and assigned to the KSM Motor Integrated Servo Drives series. By placing power electronics directly on the motor, it reduces cabinet space and cable runs while delivering closed-loop motion control for decentralized axes in automated lines. This layout supports compact machine sections where remote mounting of separate drive hardware would add complexity. It is intended for rotary positioning tasks that require tight speed accuracy, and it is part of Series 2 of the platform.
This unit accepts a supply bus of DC 750 V, so it can be tied to a common DC link shared by multiple drives. Power, feedback, and brake conductors are bundled through a single Hybrid Connector, which simplifies wiring on modular machinery and keeps connections concentrated at one entry point. Thermal management relies on natural convection, so mounting must allow free airflow along the housing instead of depending on fan-assisted cooling. Position data comes from an optical encoder that communicates through a Hiperface interface. Its scanning resolution is organized into 128 signal periods, and the encoder is a single-turn device that reports absolute position within one mechanical revolution. This feedback arrangement supports stable servo regulation during speed and position control.
Command and diagnostic traffic are routed over the Multi-Ethernet master interface, allowing the same hardware to join EtherNet/IP, PROFINET, or EtherCAT networks without change. The drive uses the standard design option in design version 1, with a basic performance level, motor size 076, and motor length C. A shaft seal is installed, and the output end is a shaft with a keyway for positive torque transfer. The unit is supplied without a holding brake, so static load retention must come from the drive or external mechanics when power is removed. The electromagnetic section uses winding code 35, which matches the motor's electrical configuration.









