


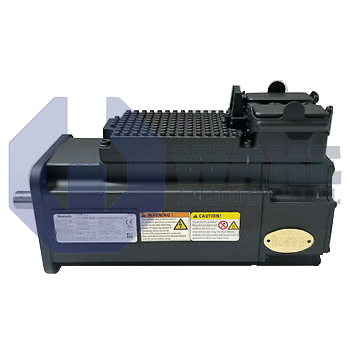
KSM02.1B-076C-35N-S1-HG2-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911389886
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-076C-35N-S1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a hybrid connector, supports Multi-Ethernet communication, and uses a supply voltage of DC 750 V. This model includes Safe Torque Off safety technology, natural convection cooling, and an electrically released holding brake with a DC 24 V voltage.
Internal Product Review
The KSM02.1B-076C-35N-S1-HG2-ET-L3-D7-NN-FW is a Bosch Rexroth Indramat motor-integrated servo drive that stands out with Multi-Ethernet communication and a DC 750 V supply. The Hiperface encoder interface and optical encoder technology support accurate feedback for refined motion performance. Safe Torque Off (STO) and an electrically released 24 V holding brake make the drive especially appealing for safety-focused servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-076C-35N-S1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. By combining a synchronous motor, encoder, drive electronics, and communication interface in one housing, the unit reduces cabinet wiring and shortens the connection path between the power stage and the motor. It is intended for decentralized motion control on packaging lines, material-handling axes, and assembly stations where compact installation is important. The integrated design also helps place the drive close to the moving axis instead of routing separate motor and feedback cables back to a central cabinet.
The drive operates from a DC 750 V bus, and winding code 35 matches the stator to this voltage class for balanced thermal loading. Power, signals, and brake lines are combined in a single Hybrid Connector, which reduces the number of separate machine connections. Feedback is transmitted through the Hiperface interface at a resolution of 128 signal periods, supporting accurate position control and stable speed regulation. Heat is removed by natural convection, so the housing releases heat to ambient air without a fan. The motor section uses size 076 with length C geometry, and it has a plain shaft with a shaft seal. The unit is built in Series 2, Version 1 with the standard design option.
An electrically released brake provides holding when control power is removed, and the brake coil is supplied with DC 24 V through the hybrid lead. Communication to the plant network uses Multi-Ethernet and supports integration with PROFINET, EtherNet/IP, or EtherCAT networks. For functional safety, the electronics include Safe Torque Off (STO), which removes torque-producing power from the motor during a stop request. This arrangement supports decentralized machine modules that need local drive electronics, reduced wiring, and a compact installation footprint.









