


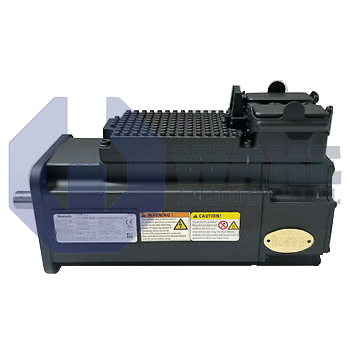
KSM02.1B-076C-35N-S1-HG0-ET-NN-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911341331
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-076C-35N-S1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive in the KSM Motor Integrated Servo Drives series. It features a Multi-Ethernet output coupling, Hiperface optical encoder with 128 signal periods, and supports a supply voltage of DC 750 V. This model uses a hybrid connector and natural convection for cooling.
Internal Product Review
The KSM02.1B-076C-35N-S1-HG0-ET-NN-D7-TO-FW is a Bosch Rexroth Indramat motor-integrated servo drive that stands out for natural convection cooling and a hybrid connector. The Multi-Ethernet design and DC 750 V supply rating make this unit a very capable choice for streamlined motion control.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-076C-35N-S1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. By combining power electronics, control logic, and the synchronous motor inside one enclosure, the device mounts directly at the axis it controls and supplies decentralized motion for packaging machines, pick-and-place gantries, and material-handling stations. This arrangement reduces cabinet space, shortens wiring runs, and delivers closed-loop positioning at the point of use in automated equipment. It is intended for installations where compact axis hardware helps simplify overall machine layout.
Electrical energy reaches the drive through a DC 750 V intermediate circuit, enabling shared bus operation with other KSM axes. A single hybrid connector carries the DC link, control wiring, and 24 V services, which simplifies installation and reduces cable count. Heat is removed by natural convection, so no fan or liquid loop is required under the stated mounting conditions. The built-in encoder uses optical sensing and exchanges data over Hiperface; with 128 signal periods and a single-turn design, it delivers an absolute rotor angle for each revolution. The motor has size 076, length C, and winding code 35, while a shaft seal protects the output shaft. The unit is delivered in design version 1 of series 2.
For control integration, the drive uses a Multi-Ethernet interface that supports EtherNet/IP, PROFINET, and EtherCAT from the same hardware. Because the servo is supplied without a holding brake, external clamping is required if static load retention is needed after power removal. The plain shaft configuration mates with keyed or clamp couplings, allowing straightforward connection to common drivetrain components. With its basic performance level, the device suits moderate dynamic requirements while keeping the overall package compact for decentralized motion applications.









