


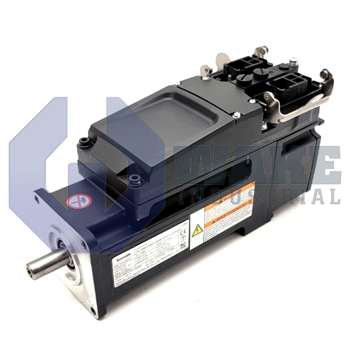
KSM02.1B-076C-35N-S1-HG0-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911389838
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-076C-35N-S1-HG0-ET-L3-D7-NN-FW belongs to the KSM Motor Integrated Servo Drives series. This motor-integrated servo drive features a hybrid connector and uses natural convection for cooling. It offers a 750 V DC supply voltage, Multi-Ethernet master communication, and an optical Hiperface single-turn encoder with a resolution of 128 signal periods.
Internal Product Review
The KSM02.1B-076C-35N-S1-HG0-ET-L3-D7-NN-FW is a motor-integrated servo drive with Multi-Ethernet communication. The Hiperface encoder and optical feedback arrangement support precise motion control and stable machine response. DC 750 V supply capability and Safe Torque Off support make the package especially attractive for high-performance, safety-focused installations.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-076C-35N-S1-HG0-ET-L3-D7-NN-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. This product combines a synchronous motor, optical feedback, and power electronics in one enclosure, enabling decentralized motion control without a cabinet-mounted drive. It mounts directly on machine frames to deliver precise torque and speed regulation for automated equipment. This arrangement also reduces the need for a separate axis amplifier and keeps the inverter stage close to the motor.
It operates from a supply bus of DC 750 V, allowing the integrated inverter stage to draw high-voltage DC directly from a common line. Power, signal, and network leads are combined in a single Hybrid Connector, which simplifies wiring between adjacent axes. Heat generated during service is dissipated through natural convection, so no fans or liquid lines are required. A single-turn optical encoder communicates over the Hiperface interface and resolves each revolution into 128 signal periods, supporting tight velocity and position loops. The device is design version 1 with a standard mechanical option, and motor length C works with winding code 35 for this configuration.
Control commands are exchanged over Multi-Ethernet, letting the drive join Ethernet-based fieldbus networks without additional interface cards. Functional safety is provided by Safe Torque Off (STO), which disables the power stage for safety-related stopping functions. The rotor ends in a plain shaft, and a shaft seal helps limit ingress, but the unit is supplied without a holding brake, so external restraint is needed when power is removed. The motor size is 076, and the optical encoder uses a single-turn format that reports position within one mechanical revolution.









