


KSM02.1B-076C-35N-M3-HG2-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911378899
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
5 Minutes
13 Seconds
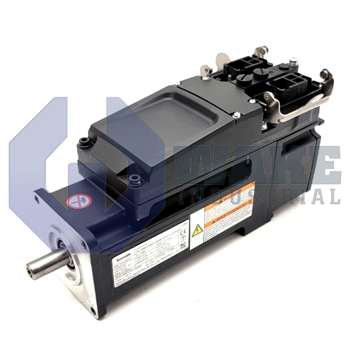
The Bosch Rexroth Indramat KSM02.1B-076C-35N-M3-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a Multi-Ethernet master communication protocol and operates with a DC 750 V supply voltage. The servo drive has a capacitive multi-turn absolute encoder using Hiperface interface, an electrically released 24 V DC holding brake, and supports Safe Torque Off safety technology.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-076C-35N-M3-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. The unit pairs a 076 frame motor of length C with embedded power electronics, so separate drive cabinets are unnecessary on distributed automation lines. Built in standard design version 1 with basic performance, it provides coordinated motion and speed control for pick-and-place stations, light conveyors, and indexing tables. Winding code 35 identifies the continuous torque class, and the enclosure supports on-machine mounting.
Electrical power is delivered through the hybrid connector at DC 750 V, and heat leaves the housing by natural convection, eliminating fans or liquid lines. Network traffic is handled by the Multi-Ethernet master interface, so PROFINET, EtherNet/IP, or EtherCAT can be selected in software. The integrated plain shaft transmits torque directly, and a shaft seal is installed to limit fluid ingress along the journal. For hold-position duties, the drive contains an electrically released brake that opens only when supplied with DC 24 V control power, allowing vertical loads to remain secure during faults. The Safe Torque Off function de-energizes the power stage without mechanical relays for personnel protection.
Position feedback relies on a Hiperface link that carries high-resolution data from the rotor. Each mechanical turn is subdivided into 16 signal periods, and the capacitive sensing method resists contamination better than optical encoders. Absolute angular information over many revolutions is provided by multi-turn absolute feedback, eliminating the need for homing after startup. The drive is in Series 2, and its electrical pinout matches other decentralized axes in the platform. This helps keep machine wiring organized on distributed motion systems.









