


KSM02.1B-076C-35N-M1-HP2-ET-SD-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911389407
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
4 Minutes
11 Seconds
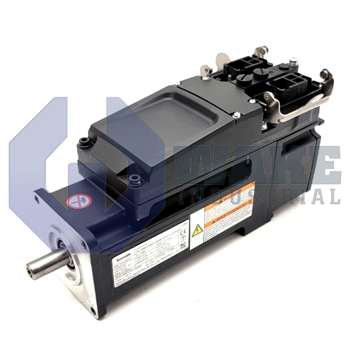
The Bosch Rexroth Indramat KSM02.1B-076C-35N-M1-HP2-ET-SD-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It uses a hybrid connector for connection and operates with a supply voltage of DC 750 V. The drive features a multi-turn absolute optical encoder with Hiperface interface and an electrically released holding brake at DC 24 V.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-076C-35N-M1-HP2-ET-SD-D7-TO-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. By combining power electronics, safety circuitry, and a 076-frame synchronous motor in one housing, the unit enables decentralized motion control on packaging, handling, and assembly machinery. It operates on a shared DC bus and regulates speed and torque directly at the axis, reducing cabinet space, cable runs, and electromagnetic interference in distributed industrial automation layouts. Because the inverter is mounted on the motor, modular machine sections can be equipped without placing a separate drive controller next to each axis.
The drive operates from a DC 750 V DC link, and this bus voltage is delivered through a single Hybrid Connector that carries both power and communication. Heat produced by the embedded inverter is removed by natural convection, so no fans are required and there are no moving cooling parts inside the drive housing. The unit is design version 1 in Series 2 with a basic performance level for general-purpose axes. Feedback is processed through a Hiperface interface that resolves the optical encoder to 128 signal periods, supporting precise position loops while keeping motor-side wiring simple. This arrangement helps the control loop track rotor position accurately during acceleration, indexing, and synchronized motion.
Holding force is provided by an electrically released brake that engages when the 24 V control line is removed, and the coil is energized from a dedicated 24 V DC source. Motion supervision uses Safe Motion (with SBC), allowing certified stop and monitoring functions. Real-time data reach the control system over Multi-Ethernet, allowing use of multiple Ethernet fieldbuses. Mechanical power is transmitted through a shaft with a keyway, and a shaft seal limits fluid ingress at the output end. The motor uses a C-length stator with winding code 35 and an optical multi-turn absolute encoder, so the axis can report absolute position across more than one shaft revolution.









