


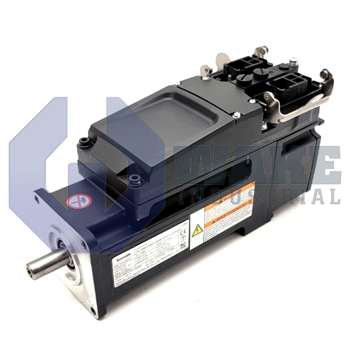
KSM02.1B-076C-35N-M1-HP2-ET-SD-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911389459
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-076C-35N-M1-HP2-ET-SD-D7-NN-FW is a motor-integrated servo drive in the KSM Motor Integrated Servo Drives series. It features a hybrid connector, uses natural convection cooling, and operates with a 750 V DC supply voltage. The device is equipped with a Hiperface optical encoder, multi-turn absolute feedback, and supports Multi-Ethernet master communication.
Internal Product Review
The KSM02.1B-076C-35N-M1-HP2-ET-SD-D7-NN-FW is a well-engineered motor-integrated servo drive featuring natural convection cooling. Multi-Ethernet communication and a Hiperface encoder support streamlined integration and dependable feedback performance. Safe Motion with SBC and an electrically released 24 V holding brake make machine safety a key strength.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-076C-35N-M1-HP2-ET-SD-D7-NN-FW belongs to the KSM Motor Integrated Servo Drives series from Bosch Rexroth Indramat. It is a motor-integrated servo drive, so the power electronics, control section, and synchronous motor are combined into one decentralized unit that streamlines cabinet wiring in automated production cells. Within an installation, the device executes position, speed, and torque control directly at the axis, which helps reduce bus latency and frees space in the main control cabinet.
This model uses a Basic performance profile and a motor size 076 stator with the longer C housing to support higher continuous torque. Winding code 35 matches the electromagnetic design to a DC 750 V DC link, allowing the drive to share a common high-power supply. Thermal losses are removed by natural convection, which eliminates the need for external fans. Multi-protocol networking is built in, and the unit uses Multi-Ethernet so it can connect to EtherNet/IP, PROFINET, or EtherCAT without added hardware. Position feedback is provided through a Hiperface optical encoder with 128 signal periods, giving the controller fine interpolation for smooth motion. The unit uses the standard design option and design version 1.
The drive incorporates an electrically released brake powered by DC 24 V; when control power is removed, spring force clamps the rotor to hold vertical axes. Functional safety is built in through Safe Motion (with SBC), which allows certified STO and SBC functions without external relays. A rugged shaft with keyway transmits torque to pulleys or couplings, and a shaft seal helps prevent lubricant escape and dust ingress. Power, signals, and Ethernet are routed through a single Hybrid Connector, which reduces cable count. Optical multi-turn absolute scanning retains position over power cycles.









