


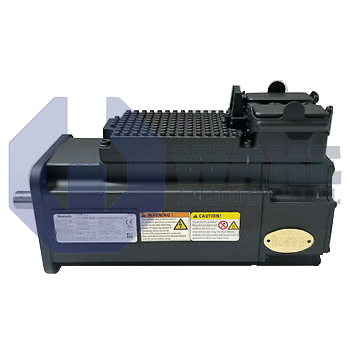
KSM02.1B-076C-35N-M1-HP0-ET-L3-D7-ES-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R914000732
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-076C-35N-M1-HP0-ET-L3-D7-ES-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a hybrid connector connection type, operates at a supply voltage of DC 750 V, and has a shaft with keyway. The drive is equipped with optical Hiperface encoder technology with multi-turn absolute resolution and uses natural convection cooling.
Internal Product Review
The KSM02.1B-076C-35N-M1-HP0-ET-L3-D7-ES-FW is a motor-integrated servo drive designed for DC 750 V supply. Optical Hiperface feedback supports accurate positioning and clean signal integrity. Multi-Ethernet communication and Safe Torque Off give the unit strong integration value for modern motion systems.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-076C-35N-M1-HP0-ET-L3-D7-ES-FW is a motor-integrated servo drive built by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. By combining a synchronous motor, drive electronics, and a fieldbus interface inside one housing, the unit streamlines decentralized axis control on modular machinery. It belongs to series 2 of the KSM platform and operates at the basic performance level, making it suitable for packaging stations, small gantries, and other medium-demand automation tasks.
Electrical power is supplied through a Hybrid Connector that routes DC link energy, logic power, and feedback signals through one plug, simplifying installation. The drive accepts a bus feed of DC 750 V, enabling direct connection to high-energy modular power supplies. Heat produced by the power stage is removed by natural convection, so no fan is required. Mechanically, the motor frame is size 076 with length code C; this footprint delivers the expected continuous torque for mid-range axes while keeping envelope dimensions small. Torque is transmitted through a shaft with a keyway, and a shaft seal is fitted to limit ingress when the motor is mounted to machinery.
Control and feedback use the External Master Communication option that supports Multi-Ethernet, allowing Profinet, EtherNet/IP, or EtherCAT on the same port for flexible controller selection. Position data comes from a Hiperface encoder that combines optical tracks and magnetic reference to provide 128 signal periods per revolution and multi-turn absolute counting. Safety integration is handled by Safe Torque Off (STO), which removes drive energy without affecting the encoder channel. The unit is delivered without a holding brake, carries winding code 35, is identified as design version 1, and relies on optical technology for its measurement path.









