


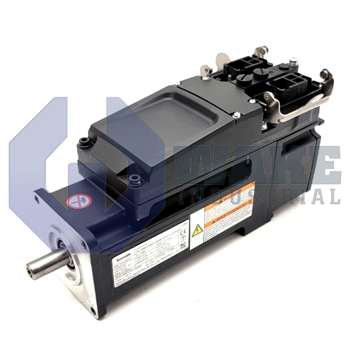
KSM02.1B-076C-35N-M1-HG0-ET-NN-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911392042
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-076C-35N-M1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series that features a hybrid connector and operates with a supply voltage of DC 750 V. It comes with a plain shaft, uses an optical multi-turn absolute encoder with Hiperface interface, and cools by natural convection.
Internal Product Review
The KSM02.1B-076C-35N-M1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive with a DC 750 V supply, well suited for streamlined machine integration. Multi-Ethernet communication and a hybrid connector make network setup and cabling especially efficient. Natural convection cooling adds welcome simplicity for compact servo drive installations.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-076C-35N-M1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. It combines a permanent-magnet synchronous motor, power stage, and fieldbus interface inside one housing so decentralized motion axes can be mounted close to the load. This arrangement shortens feedback paths, trims cabinet space, and suits conveyor, wrapper, or pick-and-place equipment that benefits from distributed servo intelligence within industrial automation. By eliminating separate drive modules, the device helps reduce wiring complexity on multi-axis machines.
Electrical power is supplied through a DC 750 V link, allowing the internal inverter to deliver full torque without local rectifiers. A single Hybrid Connector carries that supply together with control, brake, and feedback leads, streamlining field installation. Heat produced by the electronics leaves the housing through natural convection, so no forced-air components are required in the machine frame. Communication is handled through Multi-Ethernet, supporting real-time traffic over multiple industrial protocols. Position data arrives via a Hiperface interface from the optical encoder, which offers 128 signal periods per revolution for fine speed regulation. The shaft is fitted with a seal, and the assembly is delivered without a holding brake, so external mechanics must manage power-off retention. Winding code 35 and motor length C identify the electromagnetic package used for this size.
The feedback element is a multi-turn absolute device, so position counts are retained across power cycles without a homing move. This configuration belongs to the Basic performance level and is design version 1 in Series 2. With motor size 076, the stator geometry balances torque density and inertia for moderate load requirements. A plain shaft eases coupling to gears or belts in applications that need simple mechanical interfaces.









