


KSM02.1B-076C-35N-M1-HG0-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911375136
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
5 Minutes
9 Seconds
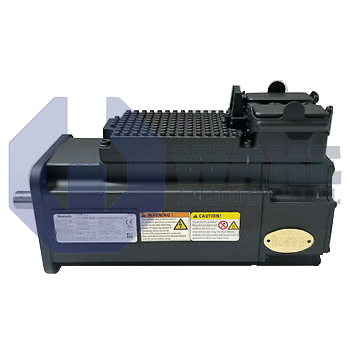
The Bosch Rexroth Indramat KSM02.1B-076C-35N-M1-HG0-ET-NN-D7-NN-FW is part of the KSM Motor Integrated Servo Drives series and features a DC 750 V supply voltage with a hybrid connector. This standard design motor-integrated servo drive uses natural convection cooling and has a plain shaft with shaft seal. It includes a multi-turn absolute optical encoder with Hiperface interface and supports Multi-Ethernet communication.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-076C-35N-M1-HG0-ET-NN-D7-NN-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. It combines drive electronics and a permanent-magnet motor in one housing, which helps simplify decentralized motion systems. By integrating the motor and drive section, the unit reduces the need for separate cabinet-mounted amplifier hardware on short-axis applications. The unit has series index 2, design version 1, and a standard design option. Motor size 076 with length code C allows installation where axial space is limited, and the basic performance level suits packaging, assembly, and material-handling axes.
Electrical power is supplied from a DC link rated at DC 750 V, matching modular IndraDrive power supplies used in multi-axis machines. The single Hybrid Connector carries power, control, and feedback lines through one connection point, reducing cable entry complexity. Heat generated by the inverter and stator is removed through natural convection, so no fans or liquid circuits are required. Position feedback is delivered through a Hiperface interface. The optical scanning method resolves the code disc into 128 signal periods, providing suitable feedback resolution for mid-range velocity loops. This arrangement supports compact machine layouts where fewer external cable runs are preferred.
The encoder stores absolute rotor position across multiple revolutions through a Multi-turn absolute system, which eliminates homing after power cycles. Real-time axis commands arrive over the Multi-Ethernet master interface, allowing support for several Ethernet-based fieldbuses on the same hardware. The interface allows common real-time network integration without separate communication hardware at the motor. Mechanical output is transmitted by a plain shaft with a shaft seal, which helps limit ingress when coolants or lubricants are present. The drive is supplied without a holding brake, so vertical axes require external holding hardware when needed. Functional safety is not integrated, and winding code 35 indicates the electrical data used by the matching drive.









