


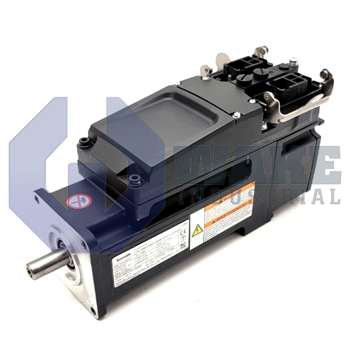
KSM02.1B-071C-35N-S1-HG0-ET-NN-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911341330
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-071C-35N-S1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a 071 size motor with natural convection cooling, a hybrid connector for connections, and operates at a supply voltage of DC 750 V. This drive has a Hiperface optical single-turn encoder with 128 signal periods and offers Multi-Ethernet communication.
Internal Product Review
The KSM02.1B-071C-35N-S1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive with natural convection cooling and a hybrid connector. Multi-Ethernet output coupling and a DC 750 V supply support clean integration in demanding machine layouts. The optical Hiperface encoder adds precise feedback, making the drive an efficient choice for compact servo systems.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-071C-35N-S1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive built by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. By combining a permanent-magnet synchronous motor and drive electronics in one housing, it supplies decentralized axis control for conveyors, packaging machines, and handling stations. This self-contained architecture reduces cabinet wiring and simplifies installation within distributed automation lines.
Supplying power over a DC link, the unit accepts a nominal input of DC 750 V, which allows it to share a common bus with other drives and minimizes rectifier losses. Power, feedback, and fieldbus signals are routed through a single Hybrid Connector, which keeps cable routing compact and reduces connection complexity. Heat generated by the embedded inverter is removed through natural convection, so mounting must allow free airflow around the aluminum body. Position feedback is handled by an optical Hiperface encoder that delivers 128 signal periods per mechanical revolution, providing fine commutation data to the internal control loop. The encoder uses an optical scanning principle that avoids magnetic hysteresis and maintains accuracy over time.
Communication with the master controller is based on Multi-Ethernet networking, which allows the unit to exchange motion data over real-time industrial Ethernet. Because the feedback device is a single-turn sensor, position is referenced after each power cycle, which suits indexing axes that home at startup. The motor section uses size code 071, length C, and winding code 35 to match the intended torque and speed range. The motor has a plain shaft with a factory-installed seal and comes without a holding brake or integrated safety technology, so motion locking and safety functions must be provided by external components.









