


KSM02.1B-071C-35N-M3-HG0-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911379571
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
4 Minutes
34 Seconds
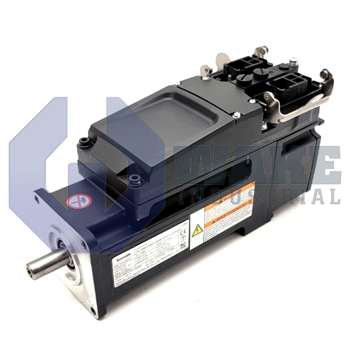
The Bosch Rexroth Indramat KSM02.1B-071C-35N-M3-HG0-ET-L3-D7-NN-FW is part of the KSM Motor Integrated Servo Drives series and is a motor-integrated servo drive with a hybrid connector and Multi-Ethernet protocol. This model features a 071 motor size, plain shaft, and natural convection cooling, operating at a supply voltage of DC 750 V. It uses a capacitive Hiperface multi-turn absolute encoder with 16 signal periods and provides Safe Torque Off safety technology.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-071C-35N-M3-HG0-ET-L3-D7-NN-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. The unit is in Series 2 and combines a servomotor with drive electronics in one enclosure to support decentralized axis control. By placing the amplifier directly on the machine, it reduces cabinet wiring and supports modular layouts in automated assembly, packaging, and material-handling cells. This arrangement also helps shorten cable runs between the drive and the moving axis, which is useful in compact machine sections where distributed motion hardware is preferred.
Electrical power is delivered over a DC 750 V common bus, and a single Hybrid Connector carries that voltage together with feedback and network conductors. Heat produced by the electronics is removed through natural convection, so external fans are not required. The mechanical envelope follows the 071 frame with motor length code C, providing a compact footprint for mid-range torque tasks. Position data is transmitted through the Hiperface interface, and the motor uses winding code 35. The motor has a plain shaft with a shaft seal, and the drive is supplied in the standard design option with design version 1 and the Basic performance level.
The internal feedback system uses a Capacitive measuring principle and resolves each revolution into 16 signal periods. A multi-turn absolute track also records complete turns for position recovery after power is removed. Command and diagnostic traffic run on Multi-Ethernet, so the device can connect to EtherNet/IP, PROFINET, or EtherCAT hosts without extra hardware. When required, Safe Torque Off (STO) disables the power stage through redundant channels that meet functional safety requirements. The axis is supplied without a holding brake, so vertical loads must be secured by external hardware during shutdown.









