


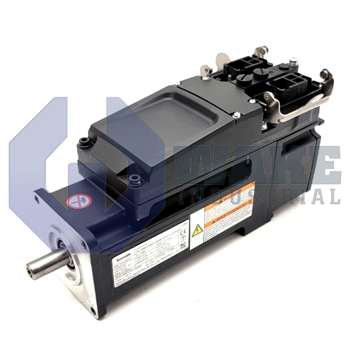
KSM02.1B-071C-35N-M1-HP0-ET-S3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911380291
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-071C-35N-M1-HP0-ET-S3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It has a motor size of 071, operates with a DC 750 V supply voltage, and uses a hybrid connector. This model includes a multi-turn absolute optical encoder with Hiperface interface and supports multi-Ethernet communication protocols.
Internal Product Review
The KSM02.1B-071C-35N-M1-HP0-ET-S3-D7-NN-FW is a Bosch Rexroth motor-integrated servo drive built for efficient axis integration and DC 750 V operation. Multi-Ethernet communication and Safe Motion without SBC give the drive strong appeal for networked systems requiring practical safety functionality. Natural convection cooling and a shaft seal support clean, low-maintenance performance, making the package a very capable servo solution.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-071C-35N-M1-HP0-ET-S3-D7-NN-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. By combining power electronics, feedback, and a synchronous servo motor in one housing, the unit streamlines mounting in distributed automation cells. It is intended to position or regulate motion axes in packaging machines, material-handling gantries, and other equipment that benefits from decentralized drive placement to shorten cable runs and reduce panel heat.
The drive operates from a bus supply of DC 750 V, and heat generated by the power stage is removed through natural convection, allowing cabinet-free installation where ambient airflow is available. A sealed Hybrid Connector carries power, safety I/O, and feedback on a single cable, while the master axis controller transfers real-time commands over Multi-Ethernet so that PROFINET, EtherNet/IP, or EtherCAT networks can be selected in software. Rotor position is captured by a Hiperface optical encoder that delivers 128 signal periods per revolution and stores absolute multi-turn data, allowing position information to remain available after power loss. Motor size 071, length C, and winding code 35 determine the electrical and mechanical combination used in this unit, and the standard design with hardware version 1 supports mid-range handling tasks.
The output shaft has a keyway and is supplied without a holding brake, so any static load must be secured by external mechanics or drive torque. A shaft seal is fitted at the nose to help limit lubricant escape and the entry of fine particles. The unit supports Safe Motion, although the configuration does not include an SBC relay. It is part of series 2 with variant S3 and uses the Basic performance class for deterministic motion control.









