


KSM02.1B-071C-35N-M1-HG0-ET-NN-D7-TO-FW Bosch Rexroth Indramat
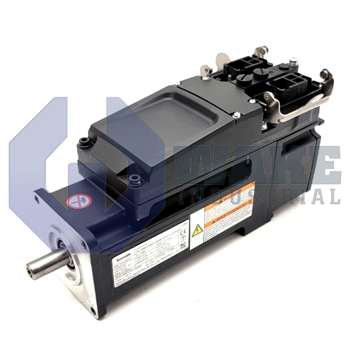
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911370449
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-071C-35N-M1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive in the KSM Motor Integrated Servo Drives series. It operates with a DC 750 V supply voltage and features a hybrid connector along with Multi-Ethernet output coupling. The servo drive uses natural convection cooling and an optical Hiperface multi-turn absolute encoder with 128 signal periods.
Internal Product Review
The KSM02.1B-071C-35N-M1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive with Multi-Ethernet communication, a strong fit for modern distributed motion systems. Natural convection cooling and a hybrid connector simplify installation and support clean integration. The Hiperface encoder interface with multi-turn absolute feedback stands out for accurate position control.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-071C-35N-M1-HG0-ET-NN-D7-TO-FW is a motor-integrated servo drive built by Bosch Rexroth Indramat and part of the KSM Motor Integrated Servo Drives series. By combining a permanent-magnet servo motor with a decentralized drive controller, the unit delivers torque, position, and velocity regulation directly on the machine frame, which reduces cabinet wiring in distributed automation layouts. This arrangement is useful when drive hardware must sit close to the moving axis rather than in a large central enclosure. It has Basic performance level and Design Version 1. Its multi-Ethernet master compatibility suits modular conveyors, pick-and-place axes, and compact packaging stations where a centralized cabinet is impractical.
The drive accepts a supply of DC 750 V, so its power stage ties into a shared DC link instead of the mains. Power, feedback, and network wiring enter through a single Hybrid Connector, which reduces cable runs and keeps connections consolidated at the motor. Thermal energy leaves through natural convection, so the housing needs unobstructed airflow around its surface. A Multi-Ethernet interface lets the unit use EtherNet/IP, PROFINET, or SERCOS III through software selection. Position data flows through a Hiperface encoder interface that supplies absolute rotor information to the integrated controller.
The measuring system is optical and resolves the shaft into 128 signal periods. It reads position as a multi-turn absolute value, so the drive retains position across power cycles and can start without a homing sequence. Mechanical output is provided by a plain shaft that couples to the machine through clamps or hubs, and a shaft seal helps limit ingress. The motor section uses size 071 with length code C and winding code 35, which suits light handling or indexing tasks. The assembly is supplied without a holding brake.









