


KSM02.1B-071C-24N-S1-HG2-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911337290
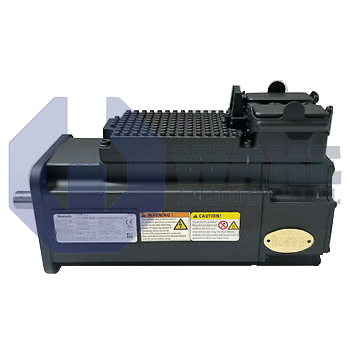
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-071C-24N-S1-HG2-ET-NN-D7-NN-FW is a motor-integrated servo drive in the KSM Motor Integrated Servo Drives series. It features a hybrid connector, Multi-Ethernet protocol, and operates with a supply voltage of DC 750 V. This drive comes with a Hiperface single-turn optical encoder and an electrically released holding brake rated at DC 24 V.
Internal Product Review
The KSM02.1B-071C-24N-S1-HG2-ET-NN-D7-NN-FW is a motor-integrated servo drive configured with natural convection cooling and a hybrid connector. Multi-Ethernet communication and a DC 750 V supply give the platform excellent compatibility with modern motion architectures. A Hiperface optical encoder adds precise feedback, making the drive a strong choice for compact servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-071C-24N-S1-HG2-ET-NN-D7-NN-FW is produced by Bosch Rexroth Indramat as part of the KSM Motor Integrated Servo Drives series. By combining the motor, power electronics, and fieldbus interface in one enclosure, this decentralized axis reduces cabinet wiring and suits conveyors, gantries, and material-handling stations. The integrated layout shortens the distance between the inverter and motor windings, which helps keep the axis package compact and reduces separate component mounting. It is Series 2 with design version 1, and its 071 frame with C-length stator supports general-purpose automation where a sealed, machine-mounted servo unit is preferred.
Power is delivered through a Hybrid Connector that groups the DC link, control, and Ethernet conductors in one plug. The inverter accepts up to DC 750 V, so it can share a common bus with IndraDrive supplies in multi-axis systems. Cooling is handled by natural convection, so airflow around the housing should remain unobstructed and no fan service is required. Motion feedback comes from a Hiperface optical encoder with 128 signal periods per revolution. This is a single-turn encoder, so absolute position is available within one mechanical revolution while the drive continues to receive the rotor information needed for controlled speed and position operation.
The axis includes an electrically released brake that is energized with DC 24 V to hold the rotor when power is removed. For controller integration, the drive offers Multi-Ethernet communication through one network interface, allowing the unit to fit control systems that use different real-time Ethernet formats. Output power is transmitted through a plain shaft, which works well with clamping hubs, pulleys, or gearbox inputs that do not require a keyed connection. A shaft seal is fitted to help protect the bearing area from contamination.









