


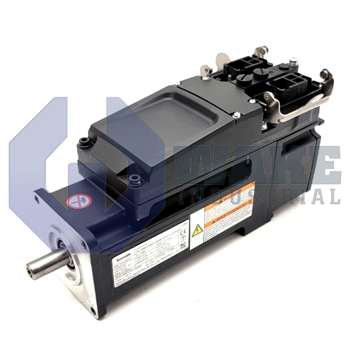
KSM02.1B-071C-24N-S1-HG2-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911341410
The Bosch Rexroth Indramat KSM02.1B-071C-24N-S1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a Multi-Ethernet master communication protocol, an optical single-turn Hiperface encoder with 128 signal periods, and an electrically released holding brake operating at 24 V DC. The servo drive supports a supply voltage of 750 V DC and provides Safe Torque Off safety technology.
Internal Product Review
The KSM02.1B-071C-24N-S1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive that stands out with natural convection cooling and a hybrid connector. Multi-Ethernet communication and Safe Torque Off (STO) give the design strong value for streamlined machine integration and dependable safety performance. A Hiperface encoder with 128 signal periods supports precise feedback, making this unit a very capable choice for integrated servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-071C-24N-S1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. It combines a 071-frame synchronous motor and an onboard inverter in one housing, so motion control, power electronics, and feedback handling do not need to be split between separate devices. This arrangement is intended for decentralized automation cells where control-cabinet space is limited and the drive must be placed close to the axis. The integrated format also helps keep the axis assembly compact on machine sections where separate drive enclosures would be difficult to place.
The drive section operates from a shared bus voltage of DC 750 V, and a single Hybrid Connector carries power, signal, and brake conductors to the unit. Network communication uses a Multi-Ethernet interface, allowing the device to work within EtherNet/IP, PROFINET, or EtherCAT systems without changing the basic hardware platform. Heat is removed by natural convection, so the housing needs open airflow around its surfaces instead of added fans. Safety shutdown is handled by Safe Torque Off (STO), which disables torque production when the safety circuit is opened.
Rotor position is captured by an optical encoder that communicates through Hiperface and provides 128 signal periods per revolution, supporting stable velocity and position control at low speed. An electrically released brake powered at DC 24 V holds vertical loads when supply power is removed, so the shaft clamps automatically in a de-energized state. Mechanical output is provided through a plain shaft, which allows the use of external couplings or pulleys without a factory-installed key. This arrangement suits applications that use clamp couplings, timing pulleys, or other external transmission components selected at the machine level.









