


KSM02.1B-071C-24N-M1-HP2-ET-S3-D7-NN-FW Bosch Rexroth Indramat
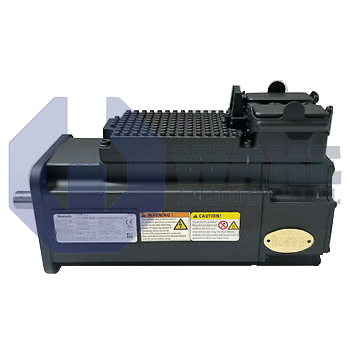
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911376344
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-071C-24N-M1-HP2-ET-S3-D7-NN-FW is a motor-integrated servo drive in the KSM Motor Integrated Servo Drives series, featuring a 071 motor size and basic performance level. It uses a hybrid connector for connection, operates with a 24 V DC electrically released holding brake, and employs Hiperface optical multi-turn absolute encoder technology. The servo drive supports Multi-Ethernet communication and is cooled with natural convection.
Internal Product Review
The KSM02.1B-071C-24N-M1-HP2-ET-S3-D7-NN-FW is a motor-integrated servo drive built for streamlined servo axis design, featuring Multi-Ethernet communication and a DC 750 V supply. Natural convection cooling and a Hiperface encoder support low-maintenance operation and accurate feedback in compact machine layouts. An electrically released holding brake at 24 V adds useful positioning security for demanding motion applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-071C-24N-M1-HP2-ET-S3-D7-NN-FW is a motor-integrated servo drive built by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. By combining a synchronous motor, power electronics, and a fieldbus interface in one housing, the unit simplifies wiring and reduces cabinet space in distributed automation zones. It is intended for positioning or velocity-controlled axes where compact drives can be mounted directly on moving machine parts.
The drive operates from a supply bus of DC 750 V, so the power section can share common DC links with other converters. All power, signal, and safety conductors are grouped in one Hybrid Connector, which helps simplify cable routing. Heat is removed through natural convection, eliminating fans and the associated maintenance. Rotor position is monitored by an optical encoder that communicates over Hiperface and delivers feedback at 128 signal periods per revolution; the multi-turn absolute design preserves position after power loss. The encoder uses optical technology, and the internal count tracks multiple turns. The motor has frame size 071 and length code C, while winding code 24 matches the motor's electrical characteristics.
Control buses connect through Multi-Ethernet, enabling selection among several real-time Ethernet protocols without hardware changes. A spring-applied, electrically released holding brake rated at DC 24 V secures vertical loads when the drive is disabled. Functional safety is implemented as Safe Motion (without SBC), allowing integrated monitoring of speed and position. Mechanical output is delivered through a shaft with a keyway, and a shaft seal is fitted to limit the ingress of lubricants or coolants. The housing uses the standard design option, and the unit is design version 1 in series 2.









