


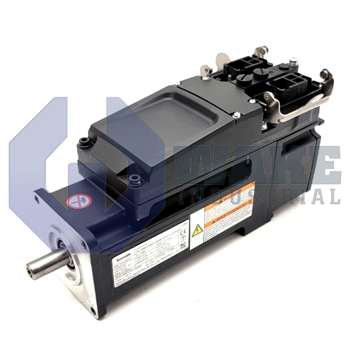
KSM02.1B-071C-24N-M1-HP0-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911370026
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-071C-24N-M1-HP0-ET-NN-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a multi-turn absolute optical encoder with Hiperface interface and supports Multi-Ethernet communication. The servo drive uses natural convection cooling and is designed with a hybrid connector and shaft with keyway.
Internal Product Review
The KSM02.1B-071C-24N-M1-HP0-ET-NN-D7-NN-FW is a motor-integrated servo drive with natural convection cooling. Multi-Ethernet communication and a DC 750 V supply make the unit especially appealing for streamlined machine integration. The Hiperface encoder provides reliable multi-turn absolute feedback, a strong advantage for precise servo positioning.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-071C-24N-M1-HP0-ET-NN-D7-NN-FW is a Bosch Rexroth Indramat unit from the KSM Motor Integrated Servo Drives series. It combines the motor and drive electronics in one housing for decentralized motion control in industrial automation. Classified as Series 2 with a standard design option and design version 1, it mounts directly on the machine frame to reduce cabinet space and simplify wiring. The unit is intended for applications such as pick-and-place heads, form-fill-seal stations, and similar equipment.
The drive operates from a centralized bus at DC 750 V, which helps limit current and heat in the supply cables. Power, control, and safety conductors are routed through a single Hybrid Connector, which keeps the connection layout compact. Communication is handled through Multi-Ethernet, and the built-in interface supports major industrial Ethernet protocols without additional cards. Rotor position feedback uses a Hiperface optical encoder that outputs 128 signal periods per mechanical turn for high-resolution interpolation in the drive. The encoder is a multi-turn absolute device, so the axis retains position when power is removed and does not require a reference move after restart. Heat is dissipated by natural convection, so airflow around the housing must remain unobstructed. The unit is supplied without a holding brake, so load securing and safe stop functions must be provided externally.
The motor uses frame code 071 with length C, which keeps the envelope compact while supporting medium torque demand. Electromagnetic behavior is set by winding code 24, which sets the current limits and temperature model used by the controller. There is a shaft seal to protect the front bearing against liquids, and the output end is a shaft with keyway for direct coupling to gears, pulleys, or belt drives.









