


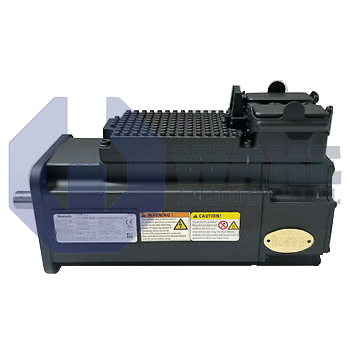
KSM02.1B-071C-24N-M1-HG2-ET-SD-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911391607
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
6 Minutes
30 Seconds
The Bosch Rexroth Indramat KSM02.1B-071C-24N-M1-HG2-ET-SD-D7-NN-FW is part of the KSM Motor Integrated Servo Drives series. This motor-integrated servo drive features a Multi-Ethernet communication protocol and uses a Hiperface optical encoder with 128 signal periods. The drive includes natural convection cooling, an electrically released holding brake at 24V DC, and operates with a supply voltage of 750V DC.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-071C-24N-M1-HG2-ET-SD-D7-NN-FW is manufactured by Bosch Rexroth Indramat as part of the KSM Motor Integrated Servo Drives series. By integrating inverter electronics with the motor housing, it decentralizes axis control and shortens cable runs in automated handling, packaging, and assembly equipment. This arrangement reduces cabinet hardware and places power conversion closer to the driven axis. This unit is assigned to Series 2, uses design version 1 with a standard design option, and provides the basic performance level for general-purpose positioning. It employs the 071 frame with the compact C length so it can fit on machines that have limited mounting space.
The drive operates from a DC 750 V bus, enabling long shared DC links between multiple axes. Internal losses are dissipated by natural convection, so external fans or liquid cooling are unnecessary. Rotor position is reported through a Hiperface channel that carries data from an optical sensor with 128 signal periods, and its multi-turn design retains absolute position after power cycles. An electrically released brake clamps the shaft whenever the control circuit is de-energized; the brake coil is powered at 24 V DC to hold loads during idle periods or emergency stops. Optical scanning and a plain shaft with a contact seal help maintain positioning accuracy while protecting the shaft area from dust and light splash.
Field integration is simplified by a hybrid connector that combines DC power, feedback, and network wiring in one cable. This combined connection layout reduces the number of separate cables routed along the machine frame. Motion commands and diagnostics travel via Multi-Ethernet, allowing the same hardware to join PROFINET, EtherNet/IP, or EtherCAT networks without option cards. Functional safety is handled through Safe Motion with an SBC channel that removes torque rapidly while the encoder continues reporting position. The motor uses winding code 24, matching its electrical characteristics to the integrated inverter section.









