


KSM02.1B-071C-24N-M1-HG0-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911345292
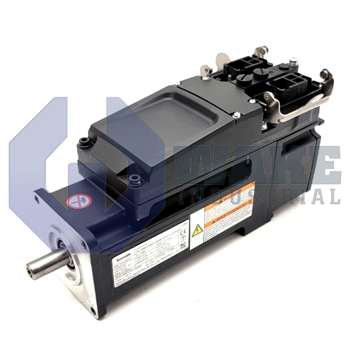
The Bosch Rexroth Indramat KSM02.1B-071C-24N-M1-HG0-ET-L3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a 071 size motor with a plain shaft, is cooled by natural convection, and operates at a supply voltage of DC 750 V. The drive supports Multi-Ethernet protocol, has a Hiperface optical multi-turn absolute encoder, and includes Safe Torque Off safety technology.
Internal Product Review
The KSM02.1B-071C-24N-M1-HG0-ET-L3-D7-NN-FW is a motor-integrated servo drive with Multi-Ethernet communication and a DC 750 V supply. Natural convection cooling and Safe Torque Off support make the unit well suited for streamlined machine builds with solid safety performance. Hiperface encoder interface and optical encoder technology support precise feedback handling, a key strength for integrated motion control.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-071C-24N-M1-HG0-ET-L3-D7-NN-FW belongs to the KSM Motor Integrated Servo Drives series and combines a servo motor with embedded drive electronics for decentralized motion control in industrial automation. It fits the series 2 mechanical platform and uses motor size 071 with length C. The unit carries the basic performance level for standard point-to-point positioning tasks and is suited to compact machine layouts that benefit from integrated drive hardware.
The power stage is supplied from a nominal bus voltage of DC 750 V, allowing direct connection to high-power common DC links. All field wiring is routed through a single hybrid connector that carries power, signal, and safety lines, which simplifies installation compared with separate connectors. Heat is removed by natural convection, so no forced-air components are needed and cabinet-free mounting remains practical where airflow is limited. Feedback is gathered through a Hiperface interface, and the optical encoder generates 128 signal periods per revolution to provide fine velocity resolution. The drive uses the standard design option and version 1, includes winding code 24, has a shaft seal, and comes without a holding brake for applications that already secure the load mechanically.
For networked installations, the controller supports Multi-Ethernet, so EtherNet/IP, PROFINET, or EtherCAT can be selected without changing the hardware. Position data are absolute because the encoder is a multi-turn absolute device, which eliminates homing moves after power cycles. Integrated safety circuitry provides Safe Torque Off (STO), enabling power removal to the motor windings through certified hardware rather than external contactors. A plain shaft with no keyway is used, favoring zero-backlash couplings in compact machine axes.









