


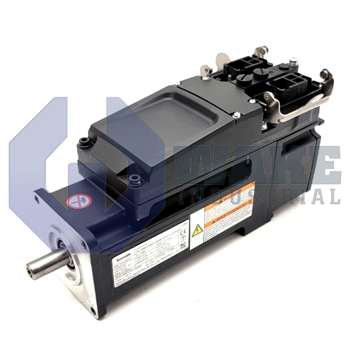
KSM02.1B-061C-61N-S3-HG2-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911337229
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-61N-S3-HG2-ET-NN-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series with a hybrid connector and uses natural convection for cooling. It features a capacitive Hiperface encoder with 16 signal periods and a single-turn design. The servo drive has an electrically released holding brake rated at DC 24 V and supports Multi-Ethernet communication protocol.
Internal Product Review
The KSM02.1B-061C-61N-S3-HG2-ET-NN-D7-NN-FW is a Bosch Rexroth Indramat motor-integrated servo drive with Multi-Ethernet communication and a DC 750 V supply. Natural convection cooling and a hybrid connector support clean integration and dependable operation in compact motion systems. A Hiperface encoder with single-turn feedback makes this drive a strong choice for straightforward servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
Bosch Rexroth Indramat manufactures the KSM02.1B-061C-61N-S3-HG2-ET-NN-D7-NN-FW as part of the KSM Motor Integrated Servo Drives Series 2. This motor-integrated servo drive combines a size 061 permanent-magnet motor with an onboard amplifier, allowing decentralized installation close to the load. By eliminating long motor cables and control-cabinet inverters, it simplifies wiring and reduces electromagnetic emissions in automated assembly cells, pick-and-place equipment, and other motion-controlled machinery.
The drive accepts a supply bus of DC 750 V, so it can be fed directly from high-power shared DC links without an intermediate transformer. Power, signal, and safety lines terminate on a Hybrid Connector, which carries both DC and fieldbus conductors in one plug to simplify installation. Heat is removed solely through natural convection, so no fan is required during operation. Command data travel over Multi-Ethernet, giving the axis deterministic exchange with EtherCAT, Sercos III, or PROFINET masters. For cyclic position feedback, the integrated sensor uses a Hiperface interface with a capacitive measuring principle that resists contamination. The motor has a C-length winding with code 61, which provides the required torque density. This model uses the standard design option and is built to design version 1.
Position accuracy is refined by an encoder that delivers 16 signal periods per revolution, and the single-turn format suits applications that index within one mechanical turn. A mechanically engaged, electrically released holding brake uses DC 24 V to release the shaft, permitting power-off clamping without external actuators. The output end uses a plain shaft, and a shaft seal is fitted to limit oil or dust ingress during washdown cycles. The drive is supplied without safety technology, so any required safety functions must be provided by external devices.









