


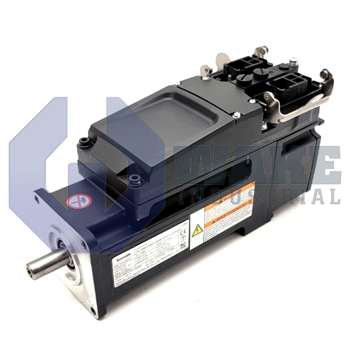
KSM02.1B-061C-61N-S1-HP0-ET-NN-D7-ES-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911381495
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-61N-S1-HP0-ET-NN-D7-ES-FW is part of the KSM Motor Integrated Servo Drives series and uses a hybrid connector for its connections. This motor-integrated servo drive features optical Hiperface encoder technology with a single-turn encoder resolution of 128 signal periods and employs natural convection for cooling. It operates with a DC supply voltage of 750 V and comes with a shaft with keyway and shaft seal, but without a holding brake.
Internal Product Review
The KSM02.1B-061C-61N-S1-HP0-ET-NN-D7-ES-FW is a Bosch Rexroth motor-integrated servo drive with natural convection cooling and a DC 750 V supply rating. Multi-Ethernet communication and a Hiperface encoder support responsive control and dependable feedback in integrated motion systems. A strong servo package for clean machine integration and consistent performance.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-61N-S1-HP0-ET-NN-D7-ES-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. By combining a permanent-magnet motor, power stage, and control electronics into one housing, it streamlines wiring and reduces panel space in distributed automation. The unit is intended for point-to-point positioning or synchronized axes where compact drives reduce cabinet heat and simplify installation on moving machine elements.
This model receives its DC bus through a Hybrid Connector that carries power, feedback, and network lines in a single plug, minimizing junction errors. It is designed for a nominal bus value of DC 750 V, enabling long cable runs between the central supply and decentralized actuators. Cooling relies on natural convection, so orientation and clearance must permit unobstructed airflow. Feedback signals are transmitted over Hiperface, and the optical encoder resolves rotor position into 128 signal periods per mechanical revolution, furnishing the controller with fine commutation data for smooth torque delivery. Master communication is handled by the Multi-Ethernet option, allowing selection among EtherNet/IP, PROFINET, EtherCAT, or SERCOS III without hardware changes.
The encoder is a single-turn encoder, providing absolute position within one revolution while eliminating maintenance associated with battery-backed memory. Mechanical output is through a shaft with a keyway, facilitating positive-drive couplings in pulleys or gearboxes, and a shaft seal is fitted to limit the ingress of fluids or dust. The unit has a Basic performance level for standard motion functions. Motor dynamics correspond to winding code 61, and the physical frame is size 061 with length C, giving moderate inertia for packaging, printing, or light assembly machinery. The unit is supplied without a holding brake, so static loads must be restrained by external mechanics or motor torque when power is off.









