


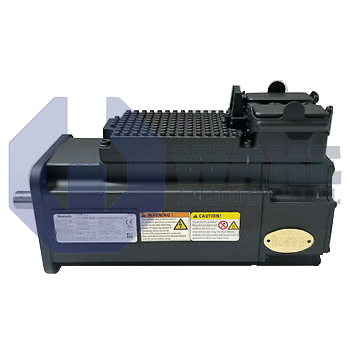
KSM02.1B-061C-61N-M3-HP2-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911343339
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-61N-M3-HP2-ET-NN-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a Hybrid Connector connection type, Multi-Ethernet communication protocol, and a supply voltage of DC 750 V. The servo drive is built with natural convection cooling, has a shaft with keyway, and includes a multi-turn absolute capacitive Hiperface encoder.
Internal Product Review
The KSM02.1B-061C-61N-M3-HP2-ET-NN-D7-NN-FW is a motor-integrated servo drive that stands out with Multi-Ethernet communication and natural convection cooling. The Hiperface encoder interface and capacitive encoder technology support stable feedback performance in coordinated motion applications. An electrically released 24 VDC holding brake rounds out a well-balanced servo package.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-61N-M3-HP2-ET-NN-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It combines drive electronics, feedback processing, and a synchronous motor in one enclosure for decentralized control of single-axis mechanisms in automated assembly, packaging, and material-handling equipment. Mounting the unit directly on the machine reduces control-cabinet heat load and shortens power and feedback cable runs. This arrangement still provides closed-loop position, speed, and torque regulation at the point of motion.
Electrical power enters through a Hybrid Connector, which carries the DC bus, control lines, and network signals through one fitting to reduce wiring. Cooling is handled by natural convection, so the housing does not require a fan and should be installed with adequate vertical clearance. The inverter section operates from a nominal DC 750 V link for distributed bus systems. Rotor position feedback is transmitted over Hiperface, and the encoder resolves 16 signal periods per mechanical rotation for stable velocity control. The parking brake uses DC 24 V power and is electrically released, so the shaft remains restrained when control power is absent.
On the network side, the drive supports Multi-Ethernet, allowing connection to PROFINET, EtherNet/IP, or EtherCAT masters without hardware changes. Encoder measurement uses a capacitive sensing element, which helps resist electromagnetic interference during operation. The stored position is available as a multi-turn absolute value with tracking for up to 4,096 turns, which removes the need for homing after power cycles. Mechanical output is transferred through a shaft with a keyway, and a shaft seal is fitted to help block fluid ingress. The unit is design version 1 with the Standard design option and Series 2, and it has size 061, length C, winding code 61, and Basic performance level.









