


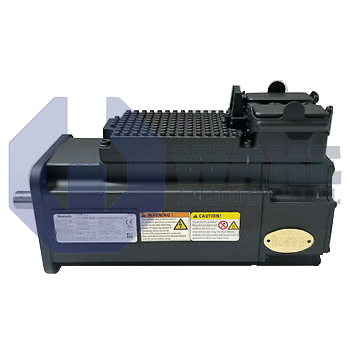
KSM02.1B-061C-61N-M3-HP0-ET-NN-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911345651
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-61N-M3-HP0-ET-NN-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a motor size of 061C, supports a supply voltage of DC 750 V, and uses a hybrid connector. This servo drive has a capacitive, multi-turn absolute Hiperface encoder without a holding brake and operates by natural convection cooling.
Internal Product Review
The KSM02.1B-061C-61N-M3-HP0-ET-NN-D7-TO-FW is a Bosch Rexroth Indramat motor-integrated servo drive that stands out for natural convection cooling and a DC 750 V supply. Multi-Ethernet communication with output coupling supports clean network integration in modern motion systems. A capacitive multi-turn absolute encoder gives this unit especially dependable feedback performance.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-61N-M3-HP0-ET-NN-D7-TO-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. By embedding the power electronics directly on the motor, the unit provides localized axis control for conveyors, pick-and-place gantries, and similar machinery, reducing enclosure size and cable runs in large automation lines. Its decentralized architecture supports modular machine layouts and reduces the need for separate drive cabinets. Because the inverter is mounted on the motor body, drive power can be placed close to the moving axis and long motor cable paths can be reduced.
Electrically, the drive runs from a DC 750 V intermediate circuit and exchanges power, feedback, and brake conductors through a single hybrid connector that simplifies installation. Thermal dissipation relies on natural convection, so no external blower or liquid circuit is required. Motion control data are handled through the Multi-Ethernet master protocol and a Multi-Ethernet output coupling, both enabled in design version 1 of internal series 2. Feedback is exchanged through the Hiperface interface, which provides 16 signal periods for commutation. Size code C indicates the motor length, while winding code 61 matches the stator to the embedded inverter for rated torque density.
The sensing subsystem uses capacitive technology and provides multi-turn absolute position feedback, so the axis retains position information after power cycles. Mechanical output is delivered through a shaft with a keyway, and a shaft seal is fitted to limit the ingress of coolant or dust. The actuator is shipped without a holding brake, so external measures are needed for power-off locking. Functional safety elements are not integrated, so external safety functions are required when the application calls for them. The 061 frame code is relevant for mounting clearances, and the basic performance level suits applications that do not require integrated safety functions.









