


KSM02.1B-061C-61N-M3-HP0-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911343337
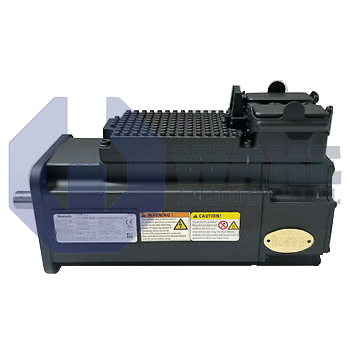
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-61N-M3-HP0-ET-NN-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series with a basic performance level and a hybrid connector. It features a Multi-Ethernet master communication protocol, a capacitive multi-turn absolute Hiperface encoder, and operates with natural convection cooling. The drive is designed with a DC 750 V supply voltage, shaft with keyway, and includes a shaft seal but does not have a holding brake.
Internal Product Review
The KSM02.1B-061C-61N-M3-HP0-ET-NN-D7-NN-FW is a Bosch Rexroth Indramat motor-integrated servo drive designed around Multi-Ethernet communication. Natural convection cooling and a hybrid connector support clean integration and dependable operation in servo applications. Hiperface feedback with multi-turn absolute encoder capability makes the unit a strong choice for precise networked motion control.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-61N-M3-HP0-ET-NN-D7-NN-FW is manufactured by Bosch Rexroth Indramat as part of the KSM Motor Integrated Servo Drives series. This second-generation unit combines a 061 frame synchronous motor in C length with an integrated inverter to decentralize axis control on machine frames. Built to the Basic performance level, the drive follows the Standard design option and is identified as design version 1. By eliminating cabinet-mounted drives, it supplies torque directly at the load and simplifies wiring in packaging, material-handling, and assembly lines.
Power is delivered from a distributed DC bus at DC 750 V, so the onboard power electronics use the 61 winding code to match insulation clearances and current capacity. A Hybrid Connector carries power, network, and safety I/O through a single pluggable interface, which simplifies installation. Heat is removed by natural convection, allowing the housing to operate without fans in vertical or horizontal mounting. Position feedback travels through the Hiperface interface, and a Capacitive scanning system generates 16 signal periods per mechanical revolution to support smooth velocity loops.
Control commands reach the drive over Multi-Ethernet, giving the controller real-time access to current, speed, and position data. The feedback element is a Multi-turn absolute encoder, so the axis reports its position after power cycling without needing an external homing routine. Mechanical power exits through a shaft with a keyway, and a shaft seal is fitted to block coolant or dust ingress at the face flange. Because the drive is supplied without a holding brake, static torque must be furnished by the servo loop or an external clamp when the machine is idle. No integrated safety technology is included, so any STO or SS1 functions must be handled by the upstream controller.









