


KSM02.1B-061C-61N-M3-HG0-ET-L3-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911391776
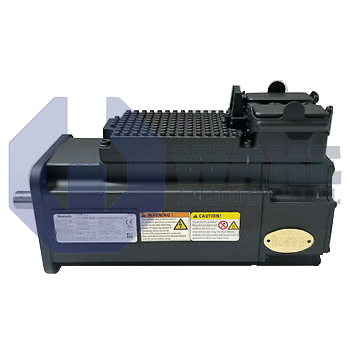
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-61N-M3-HG0-ET-L3-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a Hybrid Connector type, natural convection cooling, and supports Multi-Ethernet output coupling with Safe Torque Off safety technology. This servo drive has a Hiperface encoder interface with capacitive technology and operates on a DC 750 V supply voltage.
Internal Product Review
The KSM02.1B-061C-61N-M3-HG0-ET-L3-D7-TO-FW is a motor-integrated servo drive featuring natural convection cooling and a hybrid connector. Multi-Ethernet communication with Safe Torque Off (STO) gives the drive strong integration value for networked machinery and safety-focused installations. A capacitive multi-turn absolute encoder supports accurate feedback and stands out as a key performance advantage.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-61N-M3-HG0-ET-L3-D7-TO-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. The unit combines a permanent-magnet motor, inverter stage, and network interface in one housing, which allows decentralized installation on moving machine parts. By placing the power electronics directly on the axis, it reduces cabinet wiring and shortens encoder runs, making it suitable for modular handling systems, packaging stations, and light assembly lines where space and cabling weight are limited.
The drive accepts a bus voltage of DC 750 V, which allows direct connection to shared DC-link supplies in multi-axis systems. Heat is removed through natural convection, so the housing requires free airflow and does not use an additional fan. Power, safety, and feedback lines are combined in a single Hybrid Connector, which simplifies cable routing and reduces flex points on moving axes. Integrated functional safety is provided by Safe Torque Off (STO), so the output stage is disabled when the safety channel is activated and the motor cannot produce torque. Rotor position and speed are transmitted through a Hiperface interface, which works with the integrated multi-turn encoder to provide absolute position data after a power loss.
The encoder resolves shaft motion into 16 signal periods per revolution and tracks turns through an internal gearing mechanism. A shaft seal helps protect the plain shaft against splashing fluids, which supports use in washdown areas when suitable external sealing is applied. Stator winding code 61 is matched to the embedded inverter, and the compact frame size 061 with motor length C keeps the package small for decentralized axes. Multi-Ethernet communication allows operation on EtherNet/IP, PROFINET, SERCOS III, or EtherCAT without hardware changes. The unit has no holding brake, so static load retention must be provided by external mechanics, and it uses a plain shaft for rigid couplings in low-inertia applications.









