


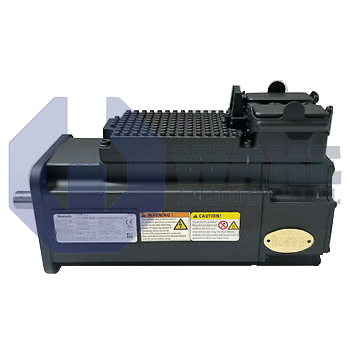
KSM02.1B-061C-61N-M1-HP2-ET-S3-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911375989
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-61N-M1-HP2-ET-S3-D7-TO-FW is a motor-integrated servo drive with a supply voltage of DC 750 V and a natural convection cooling type. Part of the KSM Motor Integrated Servo Drives series, it features a hybrid connector and Multi-Ethernet output coupling for communication. The drive uses an optical, multi-turn absolute Hiperface encoder with 128 signal periods and is equipped with an electrically released holding brake at 24 V DC.
Internal Product Review
The KSM02.1B-061C-61N-M1-HP2-ET-S3-D7-TO-FW is a Bosch Rexroth Indramat motor-integrated servo drive built for streamlined machine integration. DC 750 V supply and natural convection cooling support stable performance in demanding servo installations. Multi-Ethernet communication with Hiperface feedback adds strong control precision and integration value.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-61N-M1-HP2-ET-S3-D7-TO-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. Because the control electronics are built directly onto the motor, it reduces cabinet wiring and is installed close to the axis it actuates. Intended for industrial automation, the unit combines motion control, power stage, and feedback evaluation in a single housing to drive size 061 rotary mechanisms in assembly cells, packaging lines, and similar distributed architectures.
Power is supplied through a Hybrid Connector that carries the DC bus, control, and network lines in one plug, simplifying daisy-chain layouts. The drive accepts a supply of DC 750 V, matching the intermediate circuit voltage of Rexroth inverter groups and allowing long cable runs without additional regulators. Heat is removed solely by natural convection, so the aluminum body must remain exposed to ambient air and no fan or liquid loop is necessary. Command data travel over the Multi-Ethernet output coupling identified in design option HP2, and the interface supports EtherNet/IP, PROFINET, and SERCOS III. The unit uses a Hiperface interface that delivers feedback at a resolution of 128 signal periods, ensuring precise velocity and position loops.
The feedback system is a multi-turn absolute optical encoder, so power-off position data persist across 4096 revolutions without external batteries. Axis holding force is provided by an electrically released brake energized at DC 24 V, allowing gravity-loaded shafts to stay stationary during emergency stops. Functional safety is delivered through Safe Motion (without SBC), enabling STO and speed-limited modes directly in the drive. The unit is in series 2 with motor length C and winding code 61, and it has a keyed shaft with an integral shaft seal for direct mounting in decentralized machines.









