


KSM02.1B-061C-61N-M1-HP0-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911340799
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
5 Minutes
50 Seconds
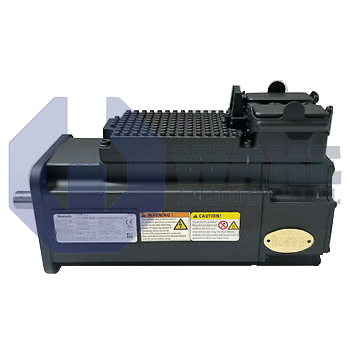
The Bosch Rexroth Indramat KSM02.1B-061C-61N-M1-HP0-ET-NN-D7-NN-FW is a motor-integrated servo drive belonging to the KSM Motor Integrated Servo Drives series. It features a 061 size motor with a C length and operates on a DC 750 V supply voltage. This standard design includes a multi-turn absolute optical encoder with Hiperface interface, a hybrid connector, and supports Multi-Ethernet communication.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-61N-M1-HP0-ET-NN-D7-NN-FW is produced by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. It merges drive electronics and the servomotor into one assembly that can be installed close to the mechanical axis, cutting cabinet size and cable runs in decentralized motion systems. This Version 1 model follows the standard mechanical option and is classified for a basic performance level, making it suitable for general conveying, pick-and-place, and handling stations that still require precise closed-loop speed and position control from a compact unit.
The unit draws power from a common direct-current bus at DC 750 V, letting several axes share regenerated energy. All power, signal, and protective earth conductors are combined in a single Hybrid Connector, which minimizes wiring effort and reduces connector count on the machine frame. Rotor position feedback is exchanged through Hiperface, and its optical sensor delivers 128 signal periods per revolution, enabling accurate velocity control even at low speed. Internal components are cooled by natural convection, so no fans or external liquid circuits are required.
Controller data exchange with the automation host is handled via Multi-Ethernet, permitting protocol selection without hardware changes. The active motor section is size 061, and torque is delivered through a hardened shaft with keyway that accepts standard taper-lock pulleys or rigid couplers. Position retention after shutdown is possible because the encoder provides multi-turn absolute data, eliminating the need for separate homing sensors. The device ships without a holding brake, relies on external mechanics when static torque is needed, and includes a shaft seal to protect the front bearing. This arrangement allows the integrated drive and motor to operate as a single axis module with minimal external hardware.









