


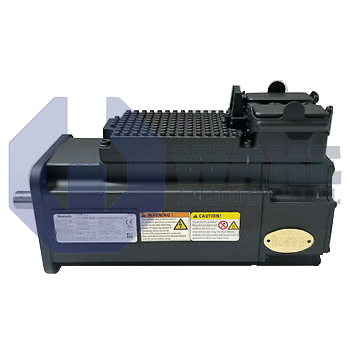
KSM02.1B-061C-61N-M1-HP0-ET-L3-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911339814
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-61N-M1-HP0-ET-L3-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a Multi-Ethernet output coupling, a hybrid connector, and operates with natural convection cooling. This model provides Safe Torque Off safety technology, a shaft with keyway, supply voltage of DC 750 V, and uses a Hiperface optical encoder with multi-turn absolute type and 128 signal periods of resolution.
Internal Product Review
The KSM02.1B-061C-61N-M1-HP0-ET-L3-D7-TO-FW is a motor-integrated servo drive with Multi-Ethernet communication and a DC 750 V supply rating. Natural convection cooling and a hybrid connector simplify machine integration while keeping the package efficient. Safe Torque Off gives the drive added safety value and rounds out a very capable servo solution.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-61N-M1-HP0-ET-L3-D7-TO-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat as part of the KSM Motor Integrated Servo Drives series. It combines a permanent-magnet synchronous motor, power electronics, and a fieldbus interface in one enclosure, reducing panel space and cable runs. Mounted directly on the machine frame, the unit receives its DC link energy from a central supply module and translates command data into tightly regulated shaft motion for indexing tables, gantry axes, and intermittent conveyor segments.
The drive accepts a bus voltage of DC 750 V, allowing high peak currents without an onboard rectifier stage. All power, signal, and safety lines are routed through a single Hybrid Connector, simplifying installation in distributed layouts. Internal losses are dissipated by natural convection, so no fan or coolant circuit is required when ambient airflow is present. Rotor position is reported through a Hiperface interface that reads an optical scale with 128 signal periods, and the multi-turn absolute design preserves revolution counts after power loss. Encoder technology is optical, motor length is coded as C, and winding code 61 sets the torque-speed curve for this axis.
Functional safety is provided by Safe Torque Off (STO), which disables the inverter switching stage through redundant channels. Network traffic arrives over a Multi-Ethernet output coupling, allowing compatibility with Sercos, EtherNet/IP, PROFINET, and EtherCAT without hardware changes. Mechanical energy is transferred through a shaft with a keyway protected by a shaft seal, and the housing uses the motor size 061 frame. The device has Basic performance level, design version 1, and series 2. It is shipped without a holding brake, so standstill retention must be provided externally.









