


KSM02.1B-061C-61N-M1-HG2-ET-S3-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911375967
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
6 Minutes
45 Seconds
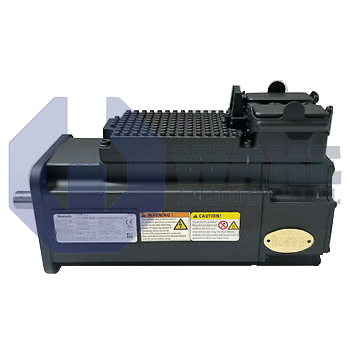
The Bosch Rexroth Indramat KSM02.1B-061C-61N-M1-HG2-ET-S3-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a Multi-Ethernet output coupling, a hybrid connector, and supports a supply voltage of DC 750 V. This drive comes with an optical Hiperface encoder, a holding brake with DC 24 V, and uses natural convection for cooling.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-61N-M1-HG2-ET-S3-D7-TO-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat and belongs to the KSM Motor Integrated Servo Drives series. It combines a permanent-magnet synchronous motor with decentralized drive electronics, so torque generation and closed-loop motion control are delivered directly at the machine axis. This arrangement reduces cabinet wiring and shortens the distance between the power stage and the motor. Because the inverter electronics are integrated into the motor housing, the unit supports a decentralized machine layout without relying on a separate nearby drive cabinet. It is intended for industrial automation systems that benefit from compact, axis-mounted drive hardware.
This unit operates from a supply bus of DC 750 V and uses natural convection for cooling, so no external fan or liquid circuit is required. Power, signal, and safety conductors are grouped in a single Hybrid Connector, which helps keep installation compact on the 061 frame. Position feedback is exchanged over a Hiperface interface, and the multi-turn absolute encoder provides 128 signal periods per mechanical revolution for precise interpolation. The motor uses size 061, length C, and winding code 61, and its basic performance level suits applications that need continuous but moderate dynamics.
The encoder uses an optical sensing method, and the drive communicates through Multi-Ethernet for integration with higher-level control systems. Status data travels within the same communication architecture used for network control. Axis holding during power loss is provided by an electrically released holding brake powered by DC 24 V. The output uses a plain shaft with a shaft seal to help protect the bearing area from contamination. Safe Motion functions without SBC are included, and the unit is design version 1 in series 2.









