


KSM02.1B-061C-61N-M1-HG2-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911336979
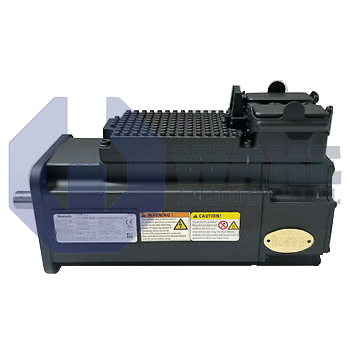
The Bosch Rexroth Indramat KSM02.1B-061C-61N-M1-HG2-ET-NN-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a plain shaft with shaft seal, a hybrid connector connection type, and natural convection cooling. The drive uses a Hiperface optical encoder with a multi-turn absolute turn type and 128 signal periods, and it supports a supply voltage of DC 750 V.
Internal Product Review
The KSM02.1B-061C-61N-M1-HG2-ET-NN-D7-NN-FW is a Bosch Rexroth motor-integrated servo drive with natural convection cooling and a standard design. Multi-Ethernet communication and a Hiperface encoder make the unit especially appealing for precise, networked motion control. An electrically released 24 V holding brake adds practical axis security, making the drive a strong choice for compact servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-61N-M1-HG2-ET-NN-D7-NN-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. By combining a permanent-magnet servomotor with onboard drive electronics, it supplies closed-loop motion control at the machine axis without a separate cabinet-mounted inverter. In automated assembly lines, packaging cells, and pick-and-place stations, the integrated format reduces wiring effort and shortens setup time at the machine axis.
The unit is powered from a DC 750 V bus, allowing several axes to share one rectifier section. All motor, feedback, and brake conductors terminate in a single hybrid connector, which simplifies cable routing at the machine. Heat is removed through natural convection, so no fans or liquid cooling circuits are required. Position feedback is delivered by an optical encoder that communicates through the Hiperface interface and generates 128 signal periods per revolution, while its multi-turn absolute design retains position data after power loss. The unit uses the standard design option, design version 1, and Series 2 construction.
The drive uses an electrically released holding brake that engages automatically when its DC 24 V brake supply is removed, securing vertical or suspended axes during power-off events. Command and diagnostic data travel over the Multi-Ethernet interface, enabling connection to EtherNet/IP, PROFINET, or EtherCAT networks with the same hardware. Mechanical sizing uses motor size 061, length code C, and winding code 61, a combination suited for light to medium packaging tasks. A plain shaft with a factory-installed shaft seal helps prevent lubricant escape while supporting direct-coupled loads. The drive is delivered in the basic performance level, offering practical motion accuracy for applications that do not require integrated safety functions.









