


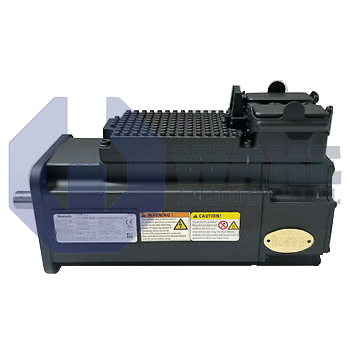
KSM02.1B-061C-35N-S1-HP0-ET-SD-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911398515
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-35N-S1-HP0-ET-SD-D7-NN-FW is part of the KSM Motor Integrated Servo Drives series and operates with a supply voltage of DC 750 V. This standard design servo drive has a size 061 motor, uses a hybrid connector, and supports Multi-Ethernet master communication protocol. It features Safe Motion safety technology with SBC, Hiperface optical single-turn encoder, and natural convection cooling.
Internal Product Review
The KSM02.1B-061C-35N-S1-HP0-ET-SD-D7-NN-FW is a Bosch Rexroth motor-integrated servo drive with Multi-Ethernet communication and a DC 750 V supply. Natural convection cooling and Safe Motion with SBC give the design efficient thermal behavior and added safety value in automated axes. A shaft seal supports long service life, making the drive a highly practical choice for streamlined servo installations.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-S1-HP0-ET-SD-D7-NN-FW is a motor-integrated servo drive built by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. It combines the motor and drive electronics in one housing to support decentralized automation with less external wiring. This layout is useful on distributed axes where cabinet space is limited and short motor cable runs are preferred. The unit uses the basic performance level and is intended for precise motion control in applications that do not rely on a centralized drive cabinet. It has frame size 061 with motor length C, winding code 35, design version 1, the standard design option, and Series 2 status.
The drive operates from a DC 750 V supply that is routed through a single Hybrid Connector, which combines power and signal connections in one interface. Heat is removed by natural convection, so the unit does not require external fans or liquid cooling. Communication is handled through Multi-Ethernet, allowing the drive to work with supported industrial Ethernet networks. Rotor position and speed are reported through the Hiperface encoder interface, which supports closed-loop motion control. The control electronics apply current limits that match the installed winding while keeping the overall package compact for machine-mounted use.
The feedback package uses an optical single-turn sensor that provides 128 signal periods per mechanical revolution, giving repeatable commutation data. Functional safety is provided through Safe Motion (with SBC), which supports controlled stop and monitored standstill functions without additional relays. Mechanical output is delivered through a shaft with a keyway, and a shaft seal helps maintain IP protection at the output. The unit is supplied without a holding brake, so load retention during standstill must be provided by external mechanics or by drive torque.









