


KSM02.1B-061C-35N-S1-HP0-ET-NN-D7-NN-FW Bosch Rexroth Indramat
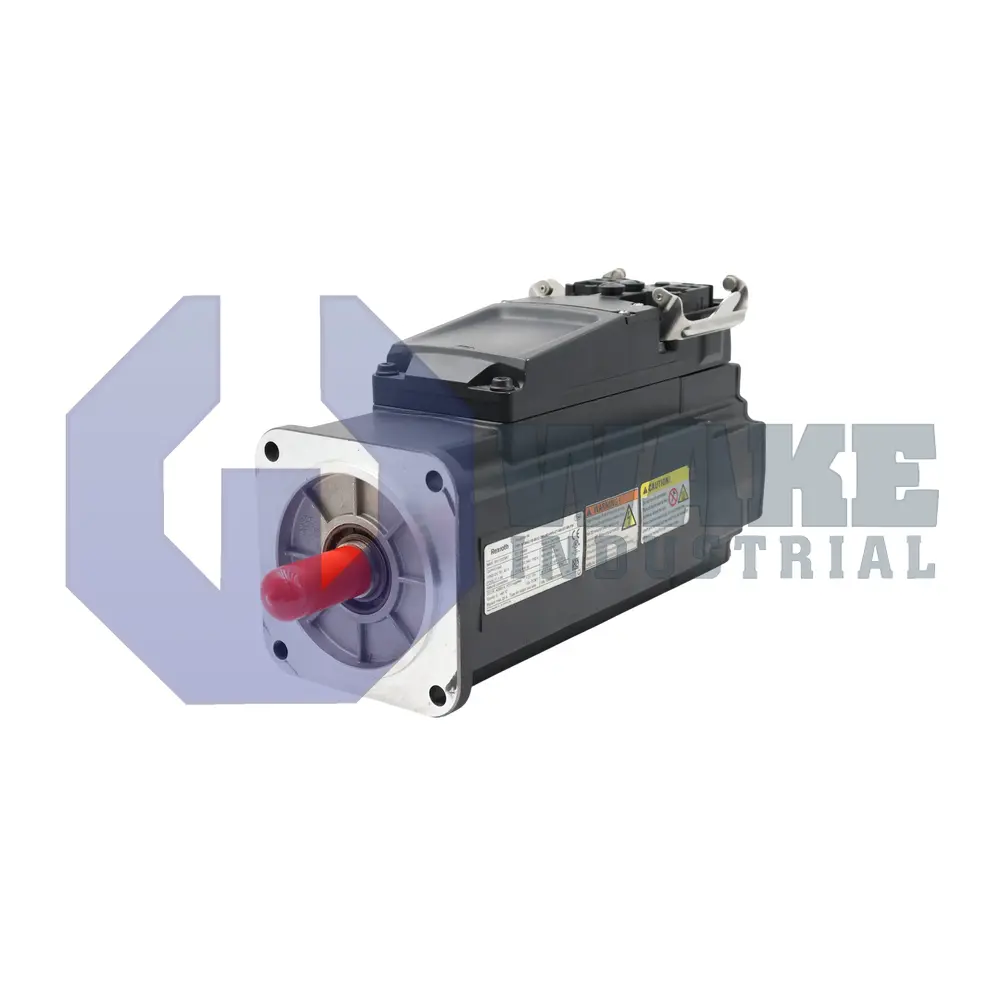
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911335833
The Bosch Rexroth Indramat KSM02.1B-061C-35N-S1-HP0-ET-NN-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series and uses a hybrid connector and Multi-Ethernet protocol. It features a 061 size motor, type C motor length, and operates on a DC 750 V supply voltage. The drive includes an optical single-turn Hiperface encoder with 128 signal periods and has a shaft with keyway, as well as natural convection cooling.
Internal Product Review
The KSM02.1B-061C-35N-S1-HP0-ET-NN-D7-NN-FW is a motor-integrated servo drive designed for efficient motion control with a DC 750 V supply. Multi-Ethernet communication gives the unit strong integration flexibility in modern automation cells. Natural convection cooling and a hybrid connector make the package especially appealing for clean, streamlined machine designs.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-S1-HP0-ET-NN-D7-NN-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. It combines a permanent-magnet servo motor and drive electronics in one housing, allowing direct installation on the machine frame for decentralized axis control. This arrangement helps reduce cabinet wiring and supports coordinated motion in packaging systems, transfer units, and other industrial automation equipment.
The drive operates from a bus supply of DC 750 V, which supports distribution over a common DC link without requiring a local converter at each axis. Heat is removed through natural convection, so the unit does not require a fan and can use a sealed housing design. Power, feedback, and communication are routed through a single Hybrid Connector, reducing the number of separate cable interfaces on the machine. Rotor position is measured by a Hiperface-compatible optical encoder that provides 128 signal periods per mechanical revolution, giving the control loop stable position and speed information during operation.
Communication with the controller is handled through Multi-Ethernet, allowing the unit to be used with PROFINET, EtherNet/IP, or EtherCAT networks through configuration. The feedback system is single-turn, so absolute position is available within one mechanical revolution after power-up. The motor uses size 061 and an output interface with a shaft with a keyway, which suits moderate torque transmission where positive shaft locking is needed. Motor length C is paired with winding code 35, and the unit is supplied without a holding brake, so a vertical axis requires external load holding when power is removed. The shaft also includes a seal to help protect the internal bearing area from contamination.









