


KSM02.1B-061C-35N-S1-HG2-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911335302
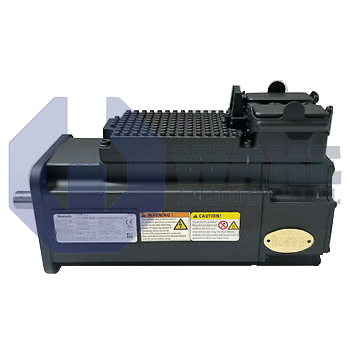
The Bosch Rexroth Indramat KSM02.1B-061C-35N-S1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a hybrid connector connection type and supports natural convection cooling. The servo drive operates with a DC 750 V supply voltage, uses Multi-Ethernet for communication, and is equipped with Safe Torque Off safety technology.
Internal Product Review
The KSM02.1B-061C-35N-S1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive that stands out with Multi-Ethernet communication and a DC 750 V supply. Natural convection cooling and Safe Torque Off support make the design especially appealing for streamlined automation systems. The optical Hiperface encoder is a strong feature for accurate feedback and dependable motion performance.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-S1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. By combining a permanent-magnet synchronous motor with an embedded power stage and fieldbus interface, the unit decentralizes motion control in packaging lines, material-handling cells, and similar systems. The product mounts directly on the machine frame, eliminating separate control cabinet wiring and providing closed-loop speed and position regulation for axis loads that fall inside its built-in drive rating. This arrangement keeps the drive electronics close to the load and reduces the amount of external cabling on moving axes.
Rated for a DC 750 V intermediate circuit, the drive draws power from a shared bus, so no individual rectifier is needed. Heat is removed through natural convection, which requires installation with clear airflow around the housing. Power, feedback, and Ethernet conductors share a Hybrid Connector, reducing moving-axis cabling and simplifying the connection path. Coordination with other axes uses the Multi-Ethernet master interface that supports common real-time networks. Drive disable is handled by the Safe Torque Off (STO) channel, which removes gating signals without interrupting the DC link. The unit uses the standard design option, design version 1, basic performance level, winding code 35, and Series 2 configuration.
Position feedback comes from a Hiperface optical sensor that yields 128 signal periods per turn and stores absolute position in single-turn format. This feedback arrangement allows the drive to recover rotor position within one mechanical revolution after power-up. The brake is electrically released, and a coil at DC 24 V frees the rotor while spring force holds it when power is off. With a frame size of 061, the unit fits compact pick-and-place axes where installation space is limited.









