


KSM02.1B-061C-35N-S1-HG0-ET-S3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911374385
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
6 Minutes
31 Seconds
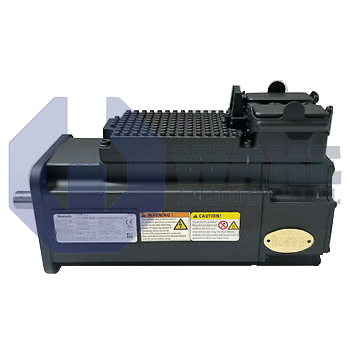
The Bosch Rexroth Indramat KSM02.1B-061C-35N-S1-HG0-ET-S3-D7-NN-FW is a motor-integrated servo drive in the KSM Motor Integrated Servo Drives series. It features a Multi-Ethernet communication protocol and operates with a supply voltage of DC 750 V. The drive uses an optical, single-turn Hiperface encoder with 128 signal periods and has a hybrid connector for connections.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-S1-HG0-ET-S3-D7-NN-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat for decentralized installation in the KSM Motor Integrated Servo Drives series. By combining an electric motor, power stage, and control electronics in one housing, the unit simplifies wiring and shortens cabinet runs in industrial automation lines that require coordinated axis control. This integrated layout also reduces the number of separate components that have to be mounted around the axis. That arrangement helps keep the drive close to the machine axis and away from long motor cable runs. It is suited to machines where compact installation and distributed drive placement are important.
This drive operates from a supply bus of DC 750 V, which matches common Rexroth IndraDrive power supplies used in multi-axis systems. Electrical and feedback conductors are collected in a Hybrid Connector, so power, signal, and safety lines leave the housing through one plug and reduce the number of panel interfaces. Heat produced by the internal inverter is removed through natural convection, allowing mounting without forced-air ducts as long as ambient airflow remains unobstructed. Position feedback is provided through the Hiperface interface, and the integrated optical encoder generates 128 signal periods per revolution for precise velocity and position control. The encoder is single-turn, so its absolute count repeats after each full rotation.
On the network side, the unit accepts motion commands over Multi-Ethernet, which supports deterministic communication for coordinated machine motion. Axis holding torque must be provided externally because it is supplied without a holding brake, which is important when the load must remain fixed after power is removed. The motor section uses size 061 with length code C and winding code 35, and it has a plain shaft with a shaft seal. The unit also includes Safe Motion without SBC for safety-related motion functions. It is design version 1 with the standard mechanical option, basic performance level, and Series 2 identification.









