


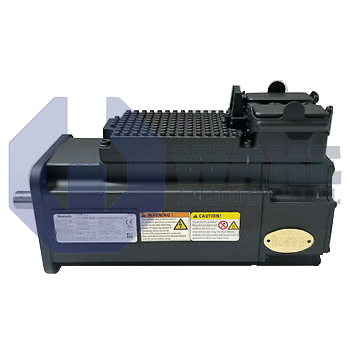
KSM02.1B-061C-35N-S1-HG0-ET-L3-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911337871
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-35N-S1-HG0-ET-L3-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a Multi-Ethernet output coupling, a Hiperface optical encoder with 128 signal periods, and operates with a DC 750 V supply voltage. The unit uses natural convection for cooling and includes Safe Torque Off safety technology.
Internal Product Review
The KSM02.1B-061C-35N-S1-HG0-ET-L3-D7-TO-FW is a motor-integrated servo drive with Multi-Ethernet communication and a hybrid connector. Natural convection cooling and a DC 750 V supply make the unit especially attractive for clean integration and stable high-performance operation. Optical Hiperface feedback is a strong feature for precise motion applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-S1-HG0-ET-L3-D7-TO-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat and supplied in the KSM Motor Integrated Servo Drives series. By embedding the power stage, control electronics, and synchronous motor into one enclosure, it delivers decentralized motion control for compact conveyor modules, pick-and-place axes, and other automated stations. This arrangement reduces cabinet space requirements and lowers wiring complexity near the machine.
This drive is powered from a shared bus at DC 750 V, so no separate rectifier is required near the axis. All power, feedback, and I/O conductors arrive through a single Hybrid Connector, which simplifies assembly and limits potential wiring faults. Thermal energy leaves the housing through natural convection; the absence of fans lowers service intervals and helps prevent dust ingestion. Position data are transferred over a Hiperface link, and the optical encoder resolves 128 signal periods per revolution, supporting precise velocity loops at low speeds. For functional safety, a hardware-based Safe Torque Off (STO) channel interrupts gate signals and removes drive torque immediately when an external safety relay trips.
Fieldbus traffic is handled through Multi-Ethernet connectivity provided by the integrated output coupling, allowing the same unit to switch between PROFINET, EtherNet/IP, or EtherCAT through parameter selection. The compact 061 frame, combined with motor length C and winding code 35, provides continuous torque for basic-performance applications, and the unit is supplied without a holding brake to keep rotor inertia lower. A shaft seal protects the internal bearings against splash and dust, and the plain shaft design allows direct coupling to gearheads or pulleys. The unit is design version 1, uses a single-turn optical encoder, has Series 2 electronics, and has a basic performance level.









