


KSM02.1B-061C-35N-S1-HG0-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911338460
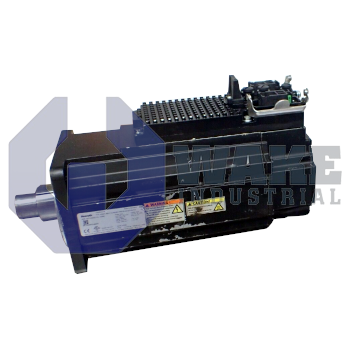
The Bosch Rexroth Indramat KSM02.1B-061C-35N-S1-HG0-ET-L3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series and operates on a DC 750 V supply voltage. This standard design drive features a hybrid connector, natural convection cooling, and supports Multi-Ethernet protocol. It includes a Hiperface optical encoder with 128 signal periods and comes with Safe Torque Off safety technology.
Internal Product Review
The KSM02.1B-061C-35N-S1-HG0-ET-L3-D7-NN-FW is a motor-integrated servo drive that stands out for Multi-Ethernet communication and natural convection cooling. An optical Hiperface encoder gives precise feedback for stable motion control. Safe Torque Off with DC 750 V supply makes the package especially attractive for safety-focused servo axes.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-S1-HG0-ET-L3-D7-NN-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat and assigned to the KSM Motor Integrated Servo Drives series. By merging power electronics, feedback, and a permanent-magnet motor in one housing, it streamlines decentralized motion axes on conveyors, packaging stations, and compact handling modules in industrial automation. Its integrated format reduces separate cabinet components and shortens cable runs between the drive electronics and the motor. The encoder works in single-turn mode, which suits applications that index within one revolution.
This drive draws power from a DC 750 V supply rail and communicates with higher-level PLCs through a Multi-Ethernet master interface that accepts several real-time Ethernet variants without additional hardware. This helps the unit fit into control networks that use different real-time Ethernet protocols. Functional safety is built in through Safe Torque Off (STO), which removes drive energy when the safety circuit opens. Rotor position is returned over a Hiperface link, and the optical encoder yields 128 signal periods per mechanical revolution to support precise speed regulation. That feedback arrangement supports stable speed control and accurate rotor commutation during dynamic motion. The unit is in design version 1 and internal design series 2, and its performance level is basic.
The unit uses motor size 061 with length C to balance torque output and footprint in restricted mounting spaces. Heat is removed by natural convection, so no forced-air accessories are required when ambient airflow is adequate. Power, signal, and brake conductors terminate on a Hybrid Connector, which reduces the number of separate cable connections on the machine. The output uses a plain shaft, and a shaft seal is present to limit dust or coolant ingress. The model is supplied without a holding brake, which suits drives that rely on mechanical clamping or vertical counterbalancing. A separate holding method is needed when the axis must remain fixed after power is removed.









