


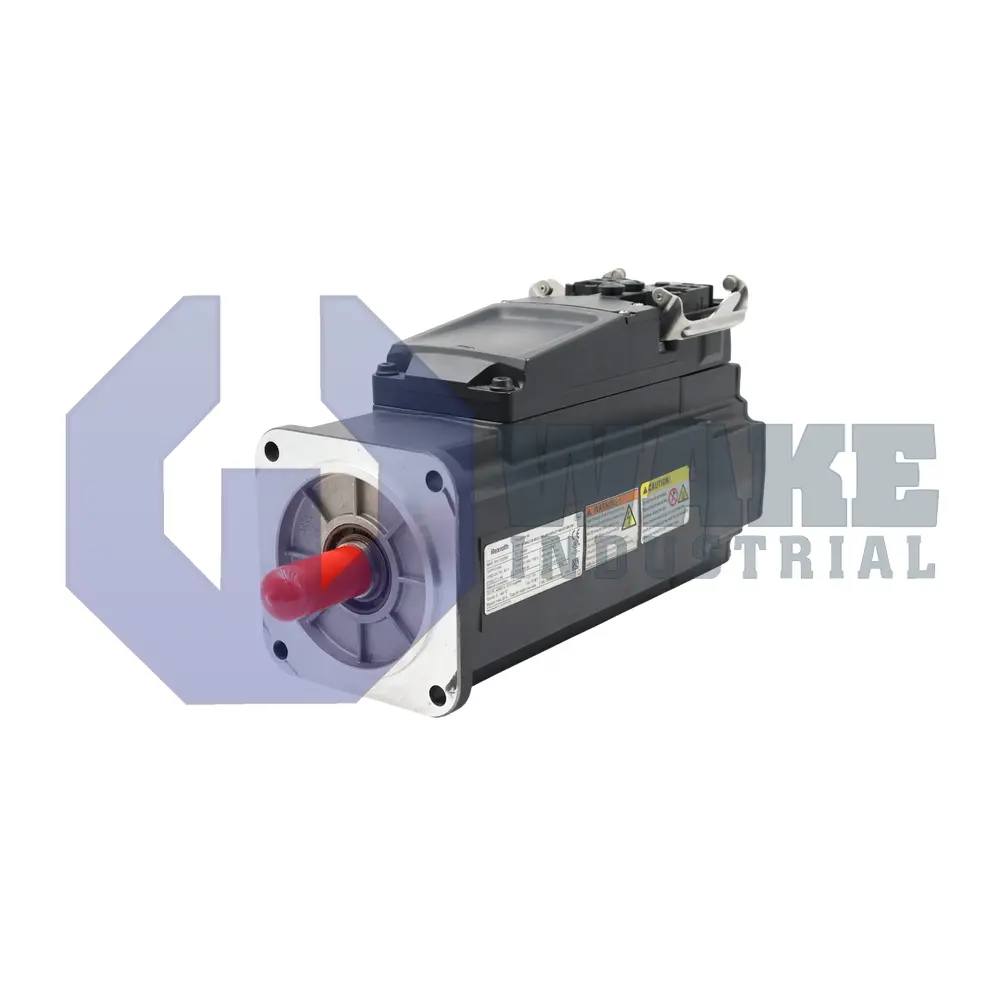
KSM02.1B-061C-35N-M3-HG2-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911346375
The Bosch Rexroth Indramat KSM02.1B-061C-35N-M3-HG2-ET-NN-D7-NN-FW is a motor-integrated servo drive in the KSM Motor Integrated Servo Drives series. It features a hybrid connector connection type, natural convection cooling, and supports a supply voltage of DC 750 V. The servo drive uses a Hiperface capacitive multi-turn absolute encoder with a resolution of 16 signal periods and has an electrically released holding brake operating at DC 24 V.
Internal Product Review
The KSM02.1B-061C-35N-M3-HG2-ET-NN-D7-NN-FW is a motor-integrated servo drive that stands out for natural convection cooling and Multi-Ethernet communication. A capacitive multi-turn absolute encoder supports dependable feedback for coordinated motion. The electrically released 24 V holding brake makes this unit a strong fit for streamlined servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-M3-HG2-ET-NN-D7-NN-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. It combines the inverter electronics with a size 061 motor in the C-length configuration, which reduces the amount of cabinet wiring needed at the machine. In factory automation, it can position tooling, index tables, or drive conveyors as a decentralized axis, while keeping the power electronics close to the mechanical load and reducing the need for a separate inverter module.
The unit runs from a DC 750 V bus, and all motor, signal, and brake leads share one Hybrid Connector to simplify cable routing at the axis. Heat leaves the housing by natural convection, so no fans or external coolers are required and the enclosure remains self-cooled during operation. Motion data moves through Multi-Ethernet ports, allowing the same hardware platform to communicate over EtherNet/IP, PROFINET, or EtherCAT, depending on the selected network environment. Rotor position reaches the drive over a Hiperface link that carries interpolation data and electronic nameplate information. The axis uses winding code 35, the standard design option, design version 1, and series 2. Its basic performance level is intended for cyclic synchronous position tasks on medium-throughput machines.
An electrically released brake energized at DC 24 V locks the shaft when power is off, which helps hold the axis at standstill. The encoder uses capacitive sensing and resolves each revolution into 16 signal periods while also storing multi-turn counts for absolute startup referencing. A plain shaft with a shaft seal helps keep coolant and dust away from the front bearing area. This model does not include integrated safety technology, so safe torque off or other safe motion functions must be provided by external equipment. The feedback system supports position retention after power cycling, which is useful on axes that need immediate startup without a separate homing move.









