


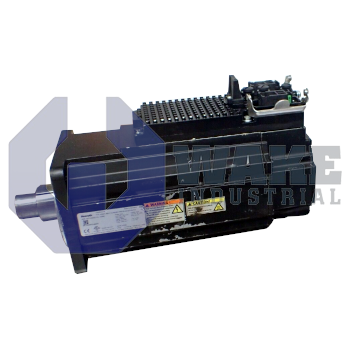
KSM02.1B-061C-35N-M3-HG2-ET-L3-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911392223
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-35N-M3-HG2-ET-L3-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a Multi-Ethernet output coupling, natural convection cooling, and includes a Hiperface encoder with capacitive technology. The servo drive operates at a supply voltage of DC 750 V and provides Safe Torque Off safety technology.
Internal Product Review
The KSM02.1B-061C-35N-M3-HG2-ET-L3-D7-TO-FW is a motor-integrated servo drive with natural convection cooling and Multi-Ethernet communication. Capacitive Hiperface feedback supports precise motion control and clean network integration. An electrically released 24 VDC holding brake rounds out an efficient and well-engineered servo package.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-M3-HG2-ET-L3-D7-TO-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. By combining the motor, inverter, feedback, and network hardware in one housing, it reduces external cabling and supports distributed motion tasks on packaging lines and compact assembly cells. The device supplies torque and closed-loop positioning directly at the axis, making it suitable for machines that need precise synchronized movement without a separate cabinet-mounted inverter. Because the power electronics are integrated into the drive body, the unit also helps simplify cable routing on compact machine layouts.
During operation, the unit is powered from a bus at DC 750 V through a single Hybrid Connector that combines power, Ethernet, and safety conductors. Heat from the internal electronics is removed by natural convection, so installation should allow unobstructed airflow and no fans or liquid coolers are required. Position data enter the control loop through a Hiperface interface that works with a capacitive multi-turn encoder and provides 16 signal periods for absolute feedback after power cycles. The motor uses size 061 with length C, giving a compact format for decentralized servo axes.
The electromagnetically released holding brake engages when power is removed and is energized with DC 24 V to secure vertical or high-load axes during stops. This brake helps hold the load at standstill when the axis is not being driven. Machine safety is supported by the embedded Safe Torque Off (STO) function, which disables motor power while communication remains active. Torque is delivered through a plain shaft with a shaft seal. The stator uses Winding code 35, and the drive operates with a multi-Ethernet interface and a basic performance profile.









