


KSM02.1B-061C-35N-M3-HG2-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911341445
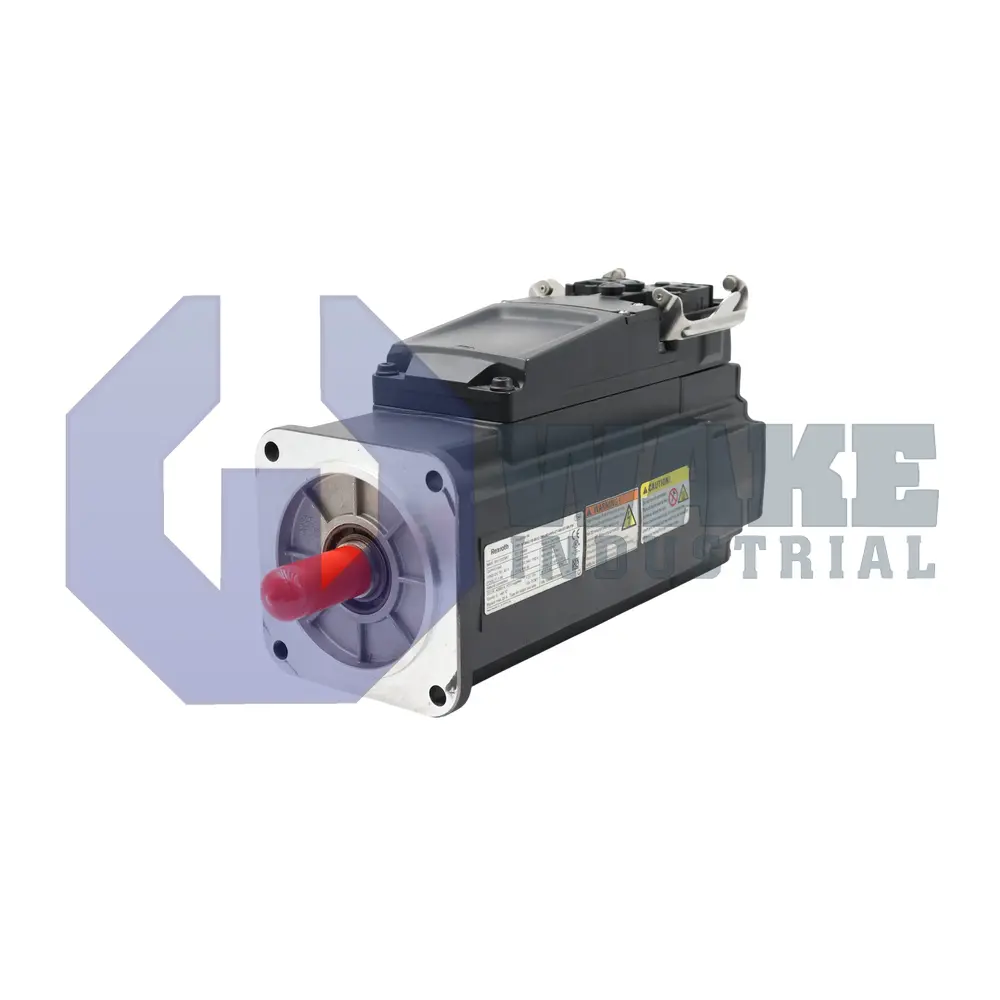
The Bosch Rexroth Indramat KSM02.1B-061C-35N-M3-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a hybrid connector, multi-Ethernet communication protocol, and operates with a supply voltage of DC 750 V. The servo drive uses natural convection cooling, includes an electrically released holding brake at DC 24 V, and supports Safe Torque Off safety technology.
Internal Product Review
The KSM02.1B-061C-35N-M3-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive built for efficient machine-level motion control, with Multi-Ethernet communication and a DC 750 V supply. Natural convection cooling and a hybrid connector support clean integration and straightforward installation. Safe Torque Off (STO) adds valuable safety, making the drive a strong choice for integrated servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-M3-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive built by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. By combining the servomotor, power electronics, and fieldbus interface in one housing, it decentralizes motion control and reduces cabinet wiring in automated assembly lines, packaging cells, and material-handling stations. It serves as an axis actuator that converts DC bus energy into precise mechanical rotation for closed-loop industrial automation tasks. The integrated layout is suited to distributed machine designs that place the drive directly at the axis instead of in a central cabinet.
It operates from a DC 750 V supply that is routed through a single Hybrid Connector, so power, control, and brake lines use one plug. Thermal energy leaves the housing by natural convection, eliminating the need for forced air or liquid cooling loops. Position feedback is handled through a Hiperface encoder that provides 16 signal periods per mechanical revolution for commutation and position tracking. The multi-turn absolute feedback retains position data after power loss, and the shaft uses a seal with a plain shaft end for coupling to pulleys or gear stages. An electrically released holding brake, energized at 24 V DC, secures the rotor during idle periods or emergency stops.
For network integration, the drive supports Multi-Ethernet, allowing connection to PROFINET, EtherNet/IP, or EtherCAT topologies without option cards. Functional safety is provided by Safe Torque Off (STO), which removes motor power without opening the DC bus. The feedback sensor uses capacitive scanning, which resists dust and vibration better than optical disks. This unit uses the standard design option, design version 1, and series 2. Its mechanical configuration uses motor size 061 with length code C and winding code 35, and the performance level is basic for this drive version.









