


KSM02.1B-061C-35N-M1-HP2-ET-S3-D7-NN-FW Bosch Rexroth Indramat
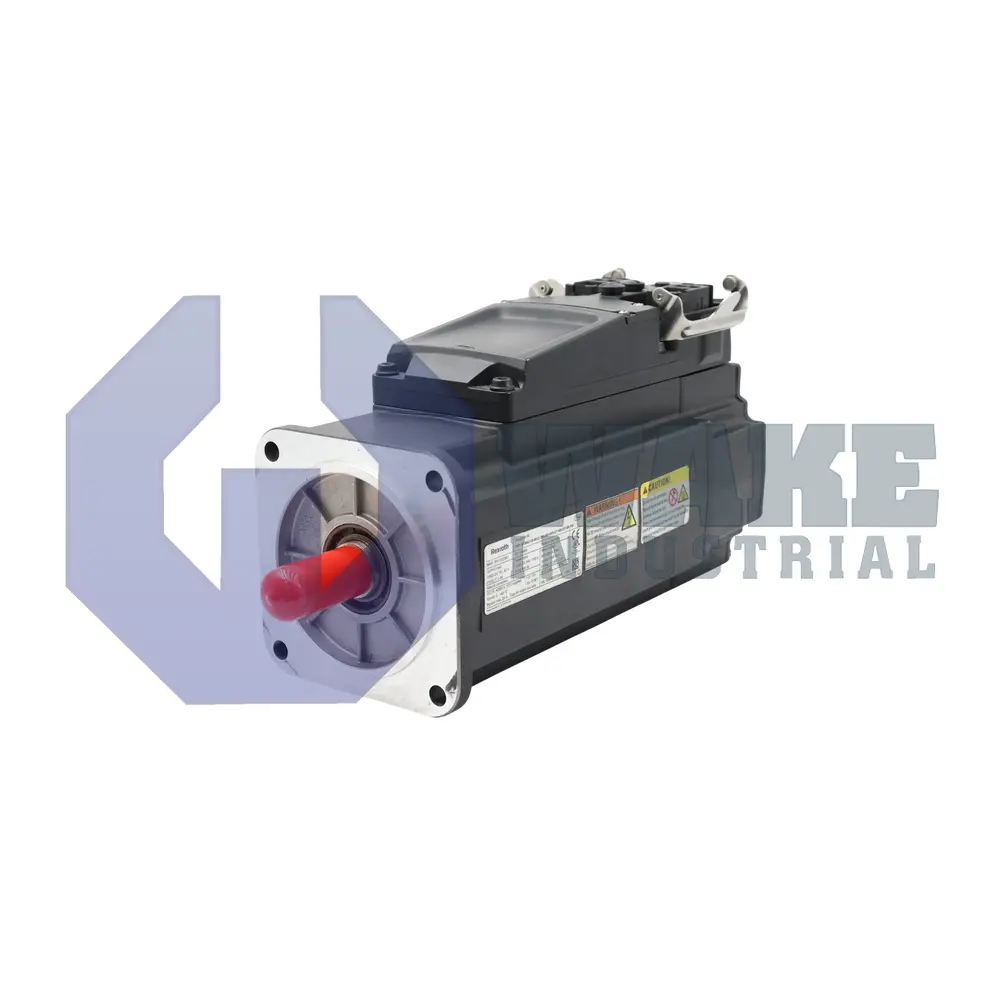
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911377209
The Bosch Rexroth Indramat KSM02.1B-061C-35N-M1-HP2-ET-S3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a hybrid connector, multi-Ethernet communication, and a Hiperface multi-turn absolute optical encoder with 128 signal periods. This unit has a holding brake that is electrically released with a DC 24 V supply, supports safe motion technology, and operates with a DC 750 V supply voltage.
Internal Product Review
The KSM02.1B-061C-35N-M1-HP2-ET-S3-D7-NN-FW is a motor-integrated servo drive with Multi-Ethernet communication for streamlined machine integration. The Hiperface encoder interface and 128 signal periods support dependable feedback quality for precise motion tasks. Natural convection cooling and Safe Motion functionality make the unit a very capable choice for integrated servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
Bosch Rexroth Indramat builds the KSM02.1B-061C-35N-M1-HP2-ET-S3-D7-NN-FW as part of its KSM Motor Integrated Servo Drives series. This integrated unit combines servo motor and drive electronics in a single housing to simplify cabinet wiring and shorten installation time on distributed machine axes. It is intended to deliver closed-loop position and speed control for packaging, handling, and assembly stations where local intelligence and reduced cable runs improve system efficiency. The motor size 061 and basic performance level match mid-range application requirements.
Energized from a system bus of DC 750 V, the drive produces torque through the 061-frame stator while limiting losses by using Natural convection cooling, eliminating the need for external fans in sealed machine zones. A single Hybrid Connector carries power, feedback, brake, and network leads so installation requires only one plug. Position feedback relies on an optical encoder with Hiperface interface; its scale delivers 128 signal periods per mechanical revolution, allowing fine cyclic interpolation for servo loops. For controller integration the unit supports Multi-Ethernet channels, enabling selection among EtherNet/IP, PROFINET, or EtherCAT without hardware changes. Together these parameters define the electrical, thermal, and communication boundaries for axis design.
To hold loads when disabled, the integrated brake is Electrically Released, engaging automatically when control power is removed and releasing at DC 24 V supplied through the hybrid plug. Functional safety is addressed by the Safe Motion (without SBC) feature set, permitting controlled stop and limited speed modes via the same fieldbus that commands motion. Additional elements such as the shaft with keyway, the internal shaft seal, the C-length stack, and design version 1 define mechanical fit and protection without altering the electrical characteristics detailed earlier.









