


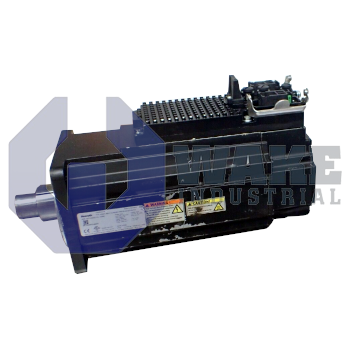
KSM02.1B-061C-35N-M1-HG2-ET-SD-D7-ES-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911346142
The Bosch Rexroth Indramat KSM02.1B-061C-35N-M1-HG2-ET-SD-D7-ES-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. This drive features a hybrid connector connection type and operates with a supply voltage of DC 750 V. It includes Multi-Ethernet master communication and natural convection cooling, with a Hiperface optical multi-turn absolute encoder for position feedback.
Internal Product Review
The KSM02.1B-061C-35N-M1-HG2-ET-SD-D7-ES-FW is a Bosch Rexroth motor-integrated servo drive with Multi-Ethernet communication and natural convection cooling. Hiperface multi-turn absolute feedback gives the drive precise position data for coordinated motion. Safe Motion with SBC and an electrically released holding brake make the package especially attractive for integrated servo axes.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-M1-HG2-ET-SD-D7-ES-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. By embedding drive electronics directly onto the 061 frame motor, it reduces cabinet space and simplifies wiring in distributed automation layouts that require compact positioning units close to the driven mechanism. Machine controllers exchange cyclic data over the Multi-Ethernet interface for real-time coordination with the axis and integration into plant control networks.
This unit operates from a DC 750 V bus supplied through a single-cable power and signal interface that uses a Hybrid Connector. Internal thermal management relies on natural convection, so no fans are mounted and surrounding airflow must remove the generated heat from the housing during operation. Position feedback is supplied by an optical Hiperface encoder that produces 128 signal periods per mechanical revolution, and the optical scanning method helps minimize drift over time. The encoder is a multi-turn absolute type, enabling the drive to recover position after power cycling without a homing move. Design version 1 uses winding code 35 and a C-length stator for the torque curve assigned to the Basic performance level.
An electrically released holding brake rated for DC 24 V secures the load when the axis is disabled, and a shaft seal is fitted to protect the bearings from coolant or dust ingress around the plain shaft. Functional safety is handled by Safe Motion (with SBC), which provides certified stop and monitoring functions without external relays in the safety chain. Series 2 supports synchronous communication on EtherNet/IP, EtherCAT, PROFINET, and SERCOS networks. The shaft geometry suits clamp or collet couplings for direct-coupled axes that benefit from low inertia.









